Part II – Derivation of General Relativity
2 General Relativity
Before Einstein formulated his famous general theory of relativity in 1915, he first developed the special theory of relativity in 1905 (see Appendix 9). In this theory, he considered only coordinate systems moving uniformly, that is, with constant velocity relative to one another. The influence of masses, and thus gravity, was not yet taken into account.
The special theory of relativity is based on two fundamental principles:
- The speed of light in vacuum is the same in every coordinate system and equals: \( c = 299\,792\,458 \,\text{m/s} \).
- The laws of physics are valid in every inertial (non-accelerating) reference frame.
In Newton’s classical theory, time was assumed to be universal: time intervals are identical in both stationary and moving systems. However, special relativity showed that this is not correct. In a moving system, time intervals proceed more slowly than in a stationary system, an effect known as time dilation.
The length of an object also changes due to motion: it decreases relative to its original rest length. This effect is called length contraction. Both phenomena are discussed in detail in Appendix 9.
These results are direct consequences of the fact that the speed of light is constant for all observers, regardless of their motion. Since time and space depend on the chosen frame of reference, Einstein unified these quantities into a single entity: spacetime.
One of the most well-known results of this theory is the famous mass–energy relation:
in which energy and mass are considered equivalent (see Appendix 9.9). In a later stage, Einstein focused on extending his theory to accelerated frames and the influence of mass. This led in 1915 to the formulation of general relativity, in which gravity is no longer treated as a force, but as a consequence of the curvature of spacetime.
For a first impression of Einstein’s final field equations, we refer to chapter 2.16, where a summary of the final formula is given. The following chapters will discuss step by step the concepts and mathematical derivations that lead to these results.
2.1 The Equivalence Principle
By studying the influence of masses, Newton formulated the law of gravitation: masses experience acceleration due to an attractive force. When comparing gravity with other fundamental forces, such as the electric and magnetic force, both similarities and important differences become apparent.
2.1.1 Electric force
The electric force arises from charges on two particles \( q_{1} \) and \( q_{2} \). Depending on the sign of the charges, they attract or repel each other. The force between the particles is given by Coulomb’s law:
where \( k_{e} \) is the electric constant and \( r \) is the distance between the charges. The resulting acceleration depends on the mass of the particle:
There is therefore an attractive force due to the charges, but the acceleration is determined by both the magnitude of the masses and the interaction.
2.1.2 Magnetic force
Magnetic forces also cause acceleration. This depends on the charge of the particle, the orientation and strength of the magnetic field, and the mass of the particle.
2.1.3 Gravity
The gravitational force between two masses \( m_{1} \) and \( m_{2} \) is given by Newton as:
where \( G \) is the gravitational constant. By analogy with the electric force, one might expect a distinction between gravitational mass \( m_{\text{grav}} \), which produces the force, and inertial mass \( m_{\text{inert}} \), which undergoes acceleration.
At first glance, there is no reason why \(m_{\text{inert},1} \equiv m_{\text{grav},1}\) should hold. However, experiments beginning with the work of Eötvös and later, much more precise equivalence-principle tests, have found no measurable violation of the equality between inertial and gravitational mass.
Another important difference with the electric force is that gravity has no positive or negative charge: the force between two masses is always attractive.
Due to the equality of gravitational and inertial mass, it follows that:
The mass \(m\) of the falling object cancels out, so that the acceleration depends only on \(M\), the mass of the attracting body (for example, the Earth). Thus, in the Newtonian approximation, freely falling massive test bodies acquire the same gravitational acceleration, independent of their mass, provided that air resistance and other non-gravitational forces are neglected.
This leads to the conclusion that the motion of an object in a gravitational field is not determined by its own mass, but by the geometry of spacetime in which it moves.
2.1.4 Einstein’s Thought Experiment
Inspired by this observation, Einstein imagined two situations:
- A person standing still on Earth experiences a gravitational acceleration \( g = 9{,}81 \,\text{m/s}^{2} \).
- A person is inside an accelerating rocket (with the same acceleration \( g \)) in empty space.
According to Einstein, these situations are locally indistinguishable: within a sufficiently small freely falling laboratory, the effects of a uniform gravitational field cannot be distinguished from those of an appropriately accelerating reference frame. This idea led to the equivalence principle. It provided an important clue that gravity should be described geometrically rather than as an ordinary force, although the equivalence principle by itself does not constitute the full theory of spacetime curvature.
2.1.5 Remark
The mass \( m \) also exerts a force on \( M \), with the following acceleration:
However, when \(M \gg m\), the acceleration of \(M\) is much smaller than that of \(m\), so that \(M\) can often be treated as approximately fixed. The forces are equal in magnitude and opposite in direction, in accordance with Newton’s third law.
In classical theory, only masses exert forces on each other. This would imply that a mass has no influence on massless particles such as photons. General relativity, however, states that masses curve spacetime, and that all objects, even massless ones, follow this curvature. Therefore, light is also deflected in a gravitational field.
2.1.6 Observational Evidence
In 1919, Arthur Eddington and his collaborators observed the apparent displacement of stars near the Sun during a total solar eclipse. The measured deflection was consistent with Einstein’s prediction of gravitational light deflection and became an important early observational test of general relativity. The measurements were limited by the observational conditions and uncertainties of the eclipse experiments; subsequent observations have tested gravitational light deflection with much greater precision. The derivation of the relativistic light-deflection effect will be given in a later experimental chapter.
2.1.7 Key Insights
- Gravity versus other forces: In Newtonian physics, gravitational acceleration is independent of the mass of a freely falling test body, whereas the acceleration produced by other forces generally depends on the properties of the object.
- Equivalence of inertial and gravitational mass: Experiments have found no measurable violation of the equality between inertial and gravitational mass.
- Mass-independent free fall: In the Newtonian approximation, freely falling test bodies acquire the same gravitational acceleration when non-gravitational forces are neglected.
- Einstein’s thought experiment: A sufficiently small laboratory in a gravitational field can locally reproduce the effects of an appropriately accelerating reference frame.
- Geometric interpretation: The equivalence principle provides the starting point for describing gravity geometrically in general relativity. The full description involves the metric, connection, curvature, and Einstein’s field equations.
2.1.8 Intuitive Explanation
Imagine you are inside a closed space, a rocket or a room without windows. If you feel yourself being pressed against the floor, you cannot determine whether you are on Earth (where gravity pulls you downward) or in space inside a rocket that is accelerating. This is the essence of the equivalence principle.
Einstein argued that, within a sufficiently small region of spacetime, a freely falling observer cannot locally distinguish the effects of gravity from those of an inertial reference frame. Conversely, an observer in a uniformly accelerating laboratory can experience effects that locally resemble those of a uniform gravitational field. This local equivalence is one of the key ideas that led to the geometric formulation of general relativity.
The qualification locally is essential. Over a sufficiently large region, or with sufficiently precise measurements, tidal effects can reveal the presence of spacetime curvature. These tidal effects cannot be eliminated merely by changing to a freely falling reference frame.
2.2 Curvature of Spacetime
To understand the significance of the transition from Newton’s classical gravitational model to Einstein’s geometric model, we first approach the subject in an alternative, more intuitive way.
Consider a particle in free space, far away from masses and without the influence of external forces. In such a situation, the particle continues to move with constant velocity in a straight line, a principle already described around 1600 by Galileo Galilei.
If we imagine spacetime as consisting of rectangular grid lines, a spatial reference framework without curvature, the particle follows a straight path along this grid. There is nothing to cause deviation from its initial direction or velocity.
Einstein proposed that the presence of matter and energy changes the geometry of spacetime. In this geometry, a freely falling object follows a geodesic: the general-relativistic analogue of a straight-line path in flat spacetime.
To a distant observer using a particular coordinate system, such a trajectory may appear curved. This does not mean that a force is acting on the freely falling object in the Newtonian sense. Rather, the object is following the natural path determined by the spacetime geometry.
The important distinction is therefore between the coordinate description of a trajectory and the underlying geometric description. A geodesic can appear curved in a chosen coordinate system while representing free fall locally.
2.2.1 From Force to Geometry
The challenge Einstein faced was to formulate the laws of physics in a coordinate-independent geometric manner. The mathematical components used to describe the geometry may change under a coordinate transformation, but the physical and geometric content of the theory must remain invariant.
This meant developing a fully coordinate-independent formulation, so that the laws of physics retain the same form in every frame, a central principle of general relativity. The effects of mass and energy on geometry would ultimately be encoded in the Einstein field equations, which describe how matter curves spacetime and how curved spacetime determines the motion of matter.
2.2.2 Independence of the Chosen Coordinate System
To determine the position of a point in space, we always need a reference, an origin from which distances are measured. A common method is to choose a Cartesian coordinate system with three mutually perpendicular axes: the x-, y-, and z-axes.
We can describe the location of a point using coordinates \( (x, y, z) \), where these values represent distances from the origin along the respective axes. The distance from that point to the origin is then, according to the Pythagorean theorem:
If we choose a different coordinate system, the numerical values of the coordinates and the individual coordinate differentials generally change. What remains invariant is the geometric interval between infinitesimally nearby events. In a flat Cartesian spatial coordinate system this interval is written as
The particular form of this expression depends on the coordinate system. The invariant geometric quantity is the interval \(ds^{2}\), while the coordinate components used to calculate it may change under a coordinate transformation.
2.2.3 Vector Approach to Distance
We can interpret the differential displacement as the sum of three vector components:
Here, \(\hat{e}_x\) denotes the unit vector along the x-axis, and \(dx\) represents its magnitude.
In Figure 2.3, it is schematically illustrated how the vector \( d\vec{s} \) can be decomposed into components along the basis vectors of the chosen coordinate system.
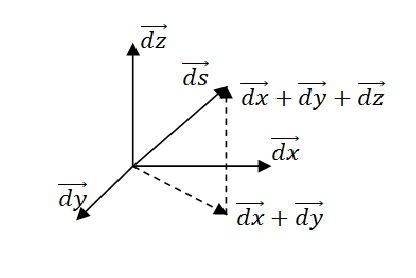
The magnitude \( ds \) of the vector \( d\vec{s} \) is obtained via the inner product \(d\vec{s} \cdot d\vec{s}\):
Reminder: the inner product of two vectors \( \vec{A} \) and \( \vec{B} \) is:
where \( \varphi \) is the angle between the two vectors.
And thus:
For the full inner product of \( d\vec{s} \), we obtain:
Or more compactly:
In an orthogonal system, the cross terms such as \( d\vec{x} \cdot d\vec{y} \) vanish, since the angles between the axes are 90° and \( \cos 90^\circ = 0 \). In that case, we simply obtain:
In a non-orthogonal coordinate system, the angles between the axes are not necessarily 90°, so the cross terms also contribute. The general form then becomes:
The coefficients \(g_{ij}\) determine the inner products between the coordinate basis vectors and therefore encode the local geometry of the space. Together they form the components of the metric tensor \(g_{ij}\). The metric determines both the lengths of vectors and the angles between them.
The metric acts like a set of geometric weighting factors: it determines how coordinate differentials combine to produce physical distances and angles.
2.2.4 Extension to Spacetime
Einstein sought an even more general formulation, for a four-dimensional system consisting of one time axis and three spatial axes. These axes need not be orthogonal, and moreover the metric may vary from point to point in spacetime. The general expression for the square of the spacetime interval is then:
Or in Einstein notation:
where:
- \( \mu, \nu = 0, 1, 2, 3 \)
- \( x^{0} = ct,\; x^{1} = x,\; x^{2} = y,\; x^{3} = z \)
- \( g_{\mu\nu} \) are the components of the four-dimensional metric tensor
In Einstein notation (where summation over repeated indices, so-called “dummy indices”, is implied), the sum is not written explicitly.
Throughout this document we use the metric signature \( (+,-,-,-) \). With this convention, timelike intervals have \(ds^{2}>0\), lightlike intervals have \(ds^{2}=0\), and spacelike intervals have \(ds^{2}<0\).
2.2.4.1 Expansion of the Sum
When we fully expand the expression (\ref{eq:R19}) for all values of \( \mu \) and \( \nu \), we obtain:
This is the four-dimensional counterpart of the earlier three-dimensional expression (\ref{eq:R2242}) (see chapter 5 for more details).
Because the metric tensor is symmetric, \(g_{\mu\nu}=g_{\nu\mu}\), several of these terms occur in equal pairs. Einstein notation allows the complete expression to be written compactly as \(ds^{2}=g_{\mu\nu}dx^{\mu}dx^{\nu}\), without explicitly writing all sixteen terms.
2.2.4.2 Remark on Symmetry
The metric tensor \( g_{\mu\nu} \) is symmetric, meaning:
In four dimensions, a symmetric \(4\times4\) metric tensor therefore has \(4(4+1)/2=10\) independent components.
2.2.5 Key Insights
- Free motion in flat spacetime: In the absence of non-gravitational forces, a freely falling test body follows an inertial trajectory in flat spacetime.
- Spacetime geometry: Matter and energy influence the geometry of spacetime. The metric tensor provides the mathematical description of this geometry.
- Geodesics: Freely falling test bodies follow geodesics, which are the general-relativistic generalization of straight-line motion.
- Coordinate dependence: The coordinate representation of a trajectory or metric may change when the coordinates are changed, while geometric quantities remain invariant.
- Einstein’s challenge: A mathematical theory was required that relates spacetime geometry to matter and energy. This ultimately leads to Einstein’s field equations.
For further details on tensors and the metric, and their application to specific cases such as the Schwarzschild solution, see chapter 5.
2.2.6 Intuitive Explanation
Imagine the following:
- A billiard ball rolls across a smooth, flat table, it moves in a straight line.
- Now place a heavy sphere on a flexible rubber sheet (like a trampoline), creating a curvature.
- If you roll a smaller ball across the sheet, it will be deflected by the deformation, even though no force is directly applied.
Important: The rubber-sheet analogy is only a visualization of curved geometry. General relativity describes the four-dimensional geometry of spacetime, not merely the curvature of three-dimensional space. In particular, the time component of the metric plays an essential role in gravitational phenomena such as gravitational time dilation and orbital motion.
According to Newton, gravity is a force acting at a distance. According to Einstein, there is no force: objects move along straight paths, but these paths lie in a curved spacetime. In this sense, a falling apple is not being pulled, but simply follows the shortest path through a curved spacetime.
2.3 Covariant and Contravariant Vectors and Dual Vectors
In general relativity, the concepts of contravariant and covariant components occur frequently. In this section, we explain these concepts and show how they arise from the transformation of vectors and covectors under a change of coordinate system.
A geometric or physical object does not depend on the coordinates used to describe it. Its components, however, generally do change under a coordinate transformation. The way these components transform depends on the mathematical type of the object. In particular, vectors have contravariant components, while covectors have covariant components.
A vector is often called a contravariant vector because its components transform contravariantly under a change of coordinates. A covector is also called a dual vector or a one-form. The term dual vector emphasizes that a covector belongs to the dual vector space and acts on vectors to produce scalars.
2.3.1 Scalar Quantities, Vectors, and Covectors
A scalar quantity, such as temperature, has a value at every location but no direction. A collection of scalars across space forms a scalar field. When such a field varies from one location to another, we can take its derivative. This derivative is naturally a covector, also called a dual vector or one-form. It takes a vector as input and produces a scalar: specifically, the directional derivative of the scalar field in that direction.
The components of this covector are \( \partial\varphi/\partial x^{\mu} \), and the differential can be written as \[ d\varphi = \frac{\partial\varphi}{\partial x^{\mu}}\,dx^{\mu}. \] Thus, the covector \(d\varphi\) is naturally an element of the dual vector space.
A covector depends on the chosen coordinate system. Under a coordinate transformation, its components transform in such a way that the covector itself remains the same geometric object. These components are therefore called covariant.
A “normal” vector, such as velocity or acceleration, behaves differently. When the coordinate system changes, the physical vector remains the same, but its components transform oppositely to the basis vectors. Such vectors are called contravariant.
Thus, the terminology can be summarized as follows:
| Object | Alternative name | Components | Index notation |
|---|---|---|---|
| Vector | Contravariant vector | Contravariant components | \(V^{\mu}\) |
| Covector | Dual vector, one-form | Covariant components | \(V_{\mu}\) |
The distinction is therefore not simply a matter of whether an index is written upstairs or downstairs. The upper and lower indices indicate two different transformation behaviors under a change of coordinates. The metric tensor can subsequently be used to relate vectors and covectors by raising and lowering indices.
2.3.1.1 Notation and Definitions
It is important to distinguish between a vector and a covector. A vector \(A^{\mu}\) belongs to the tangent space, whereas a covector \(A_{\mu}\) belongs to the dual vector space. The metric provides a mapping between these spaces:
Thus, lowering an index with the metric does not merely change the notation: it uses the metric to map a vector to its corresponding covector.
The contraction of a vector with its metric-associated covector produces a scalar:
This scalar is invariant under a coordinate transformation. For a spacetime vector, its sign determines whether the vector is timelike, spacelike, or lightlike, according to the signature convention \( (+,-,-,-) \):
- Timelike: \(A^{\mu}A_{\mu} > 0\)
- Spacelike: \(A^{\mu}A_{\mu} < 0\)
- Lightlike: \(A^{\mu}A_{\mu} = 0\)
2.3.2 Transformations Between Coordinate Systems
Suppose we work in a coordinate system with coordinates \( x^{m} \) (where \( m = 0,1,2,3 \)), and we transform to a new coordinate system with coordinates \( y^{n} \). The relation between the two systems is given by:
In Einstein notation, where summation over repeated indices (from 0 to 3) is implicit, this becomes:
2.3.2.1 Example: Derivative of a Scalar Function
Consider a scalar function \( \varphi \). Its differential is:
Fully expanded:
In the new coordinate system \( y^{n} \), we use the chain rule to transform the components of the derivative:
The components of the differential therefore transform as:
where:
- \( A_{n}(y) = \dfrac{d\varphi}{dy^{n}} \): the covariant vector in the \(y\)-system,
- \( B_{m}(x) = \dfrac{\partial \varphi}{\partial x^{m}} \): the covariant vector in the \(x\)-system.
This is a covariant transformation.
2.3.2.1.1 Fully Expanded (Matrix Form)
In matrix form, equation (\ref{eq:R23215}) becomes:
2.3.2.2 Contravariant Transformation
For contravariant vectors, the transformation formula is reversed:
Fully written out in matrix form:
2.3.3 Transformation Behavior of Basis Vectors
In tensor calculus, it is important not only to understand how the components of a vector change under a coordinate transformation, but also how the associated basis vectors themselves transform.
When changing coordinates from \( x^{m} \) to \( y^{n} \), the corresponding basis vectors are:
- \( \vec e_{m} = \dfrac{\partial}{\partial x^{m}} \)
- \( \vec f_{n} = \dfrac{\partial}{\partial y^{n}} \)
The relationship between basis vectors in different coordinate systems follows from the chain rule of calculus:
The coordinate basis vectors transform according to the Jacobian \( \partial y^{n}/\partial x^{m} \). The components of a contravariant vector transform with the inverse Jacobian so that the geometric vector itself remains unchanged.
2.3.3.1 Remark on Einstein Notation
Einstein notation makes use of repeated indices (so-called dummy indices), where summation is automatically implied over the values 0 through 3:
In this section, many expressions are written out explicitly to clarify the meaning of this notation. In later chapters, we will more frequently use the compact Einstein notation.
2.3.4 Key Points
- Scalars versus vectors:
- A scalar quantity (such as temperature) does not depend on the choice of coordinates.
- A vector has both direction and magnitude. Its components change under a coordinate transformation, but the geometric vector itself remains the same physical object.
- Vectors are also called contravariant vectors, because their components transform contravariantly.
- Contravariant vectors:
- A vector is an element of the tangent space and is conventionally written with an upper index, such as \(A^{\mu}\).
- Examples include the four-velocity \(u^{\mu}\) and displacement vector components \(dx^{\mu}\).
- Under a coordinate transformation \(x^{\mu} \rightarrow y^{\nu}\), the components transform according to:
\begin{align} A^{\nu}(y) = \frac{\partial y^{\nu}}{\partial x^{\mu}} A^{\mu}(x) \end{align}
- Covectors, dual vectors, or one-forms:
- A covector (also known as covariant vector) is an element of the dual vector space. Covectors are therefore also called dual vectors or one-forms.
- A covector acts on a vector and produces a scalar.
- Examples include the differential \(d\varphi\) and the gradient components \(\partial_{\mu}\varphi\) (\( = \frac{\partial \varphi}{\partial x^{\mu}}\)).
- Its components are conventionally written with a lower index, such as \(A_{\mu}\), and transform covariantly:
\begin{align} A_{\nu}(y) = \frac{\partial x^{\mu}}{\partial y^{\nu}} A_{\mu}(x) \end{align}
- Duality:
- Covectors belong to the dual vector space and act linearly on vectors to produce scalars.
- For example, if \(A_{\mu}\) is a covector and \(V^{\mu}\) is a vector, their contraction
\begin{align} A_{\mu}V^{\mu} \end{align}is a scalar.
- Conversion between covariant and contravariant components:
- The metric tensor \(g_{\mu\nu}\) provides a mapping between vectors and covectors:
\begin{align} A_{\mu} = g_{\mu\nu}A^{\nu}, \qquad A^{\mu} = g^{\mu\nu}A_{\nu} \end{align}
- Thus, once a metric is given, a contravariant vector \(A^{\mu}\) can be associated with a corresponding covector \(A_{\mu}\), and vice versa.
- The metric tensor \(g_{\mu\nu}\) provides a mapping between vectors and covectors:
2.3.5 Intuitive Explanation
Imagine standing on a hill and describing the geometry of the surface using coordinate axes. The physical surface does not change when the coordinates are changed, but the numerical components used to describe vectors and covectors generally do.
A vector describes a direction and magnitude in the tangent space. A covector, also called a dual vector or one-form, acts on a vector and produces a scalar. For example, the differential of a scalar field, \(d\varphi = \frac{\partial \varphi}{\partial x^{\mu}} dx^{\mu}\), is naturally a covector.
The metric tensor provides a mapping between vectors and covectors. It allows a contravariant vector \(A^{\mu}\) to be associated with the covector \(A_{\mu}\) according to:
This mapping is a consequence of the metric structure of spacetime. The vector and its associated covector are related by the metric, but they are not the same mathematical object.
Comparison Table
| Property | Vector | Covector |
|---|---|---|
| Index position | Upper \(A^{\mu}\) | Lower \(A_{\mu}\) |
| Mathematical space | Tangent space | Dual vector space |
| Also called | Contravariant vector | Dual vector / one-form |
| Transformation | Opposit to basis | Along with basis |
| Example | Position, velocity | Gradient, differential |
| Metric relation | \(A^{\mu}=g^{\mu\nu}A_{\nu}\) | \(A_{\mu}=g_{\mu\nu}A^{\nu}\) |
| Origin | Direction in space | Directional derivative of a scalar field |
2.4 Covariant and Contravariant Transformations of Tensors
In general relativity, and more broadly in tensor analysis, covariant, contravariant, and mixed tensors play a central role. Their transformation properties under a change of coordinates allow physical and geometric laws to be expressed independently of the particular coordinate system used to describe them.
The transformation rules discussed here are a direct extension of the rules for vectors and covectors introduced in the previous section. Each upper index contributes a contravariant transformation factor, while each lower index contributes a covariant transformation factor.
2.4.1 Covariant Tensors
A covariant tensor has one or more lower indices, such as \(T_{mn}\). As an example, the tensor product of two covectors \(A_m\) and \(B_n\) produces a rank-2 covariant tensor:
The transformation of a covariant tensor from a coordinate system \(x\) to a new system \(y\) proceeds as follows:
The result of the transformation from \( T_{rs} \) to \( T_{mn} \) is then given by:
Here:
- \( T_{mn}(y) \): the covariant tensor in the new coordinate system \(y\),
- \( \dfrac{dx^{r}}{dy^{m}} \) and \( \dfrac{dx^{s}}{dy^{n}} \): the Jacobian components of the transformation from \(y\) to \(x\),
- \( T_{rs}(x) \): the original covariant tensor in the old system.
2.4.2 Contravariant Tensors
A contravariant tensor has one or more upper indices, such as \(T^{mn}\). As an example, the tensor product of two vectors \(A^m\) and \(B^n\) produces a rank-2 contravariant tensor.
The transformation is opposite to that of the covariant tensor:
The result of the transformation from \( T^{rs} \) to \( T^{mn} \) is then given by:
This formula indicates how the components of a contravariant tensor adjust under a change of basis.
2.4.3 Mixed Tensors
A mixed tensor contains both upper and lower indices, for example \( T^{m}{}_{n} \). Such a tensor can arise, for instance, from the product of a contravariant vector \( A^{m} \) and a covariant vector \( B_{n} \).
The corresponding transformation formula is:
Thus, the transformation of a mixed tensor is:
This mix of derivatives reflects the combined behavior of the different types of indices.
2.4.4 Key Points and Intuition
- A tensor is characterized by its type and by the number (rank) and position of its covariant and contravariant indices.
- Tensors provide a natural language for expressing physical and geometric laws in a form that is independent of the particular coordinate system.
- The transformation properties of a tensor ensure that the geometric or physical object it represents retains the same meaning when the coordinates are changed.
Rank and Notation
- A tensor of rank 0 is a scalar quantity, such as temperature or mass. It does not change under coordinate transformations.
-
A vector is a tensor of rank 1 with contravariant components:
- Contravariant vector: denoted with an upper index, for example \(V^{m}\).
-
A covector is a rank-1 tensor belonging to the dual vector space:
- Covector: denoted with a lower index, for example \(V_{m}\).
-
A rank-2 tensor may have different index structures:
- Fully covariant: \(T_{\mu\nu}\),
- Fully contravariant: \(T^{\mu\nu}\),
- Mixed: \(T^{\mu}{}_{\nu}\), etc.
Transformation Properties
A tensor is defined by its transformation law under a change of coordinates. These transformation rules ensure that the geometric or physical object represented by the tensor retains the same meaning when a different coordinate system is used.
- Covariant indices (lower indices) transform with \( \partial x/\partial y \).
- Contravariant indices (upper indices) transform with \( \partial y/\partial x \).
- Mixed tensors contain both types of indices and therefore combine the two transformation rules.
The metric tensor provides a mapping between vectors and covectors, allowing indices to be lowered or raised:
Thus, raising or lowering an index is not merely a change of notation. It uses the metric to map between the tangent space and its dual space.
Physical Relevance
The fundamental equations of physics, such as Einstein’s field equations in general relativity, are formulated using tensors. Their tensorial form ensures that the equations retain the same geometric and physical meaning under a change of coordinates. This covariance is essential for a theory in which coordinates are arbitrary descriptions rather than physical structures.
Intuitive Picture
You can compare tensor transformations to redrawing a map:
- Imagine a topographic map with hills, valleys, and wind directions.
- You rotate the map by 30°, but the hills remain where they are, only the coordinates used to describe them change.
Tensors behave like measurable structures in that world:
- A vector arrow on the map (e.g. wind direction) gets new coordinates after the rotation, so that the physical direction remains the same.
- A gradient (e.g. the slope of the landscape) still points upward, but is now described with different components, depending on the new axes.
This illustrates the essential idea of tensor transformations: the geometric or physical object remains the same, while its components change according to the coordinate system used to describe it.
Overview of Transformations
| Tensor type | Index notation | Transformation from \(x\) to \(y\) |
|---|---|---|
| Scalar | \(\phi\) | \(\phi(y)=\phi(x)\) |
| Contravariant vector | \(V^{\mu}\) | \(V^{\mu}(y)= \dfrac{\partial y^{\mu}}{\partial x^{\nu}}V^{\nu}(x)\) |
| Covector | \(V_{\mu}\) | \(V_{\mu}(y)= \dfrac{\partial x^{\nu}}{\partial y^{\mu}}V_{\nu}(x)\) |
| Covariant rank-2 tensor | \(T_{\mu\nu}\) | Two covariant transformation factors |
| Contravariant rank-2 tensor | \(T^{\mu\nu}\) | Two contravariant transformation factors |
| Mixed tensor | \(T^{\mu}{}_{\nu}\) | One contravariant and one covariant transformation factor |
2.5 Christoffel Symbols and the Covariant Derivative
To describe gravity as a geometric phenomenon, Einstein needed a mathematical framework for describing how vectors and coordinate bases change from point to point in spacetime. The Christoffel symbols play a central role in this framework. They describe the coefficients of the connection associated with a chosen coordinate basis and enter the definition of the covariant derivative.
Christoffel symbols are not tensors and do not themselves represent spacetime curvature. Curvature is represented geometrically by the Riemann curvature tensor, which is constructed from the connection and its derivatives. This distinction between connection and curvature is fundamental throughout general relativity.
2.5.1 Basic Definition of the Christoffel Symbols
Consider a coordinate system \(x^{\mu}\) on spacetime with associated coordinate basis vectors
In general, these basis vectors need not remain unchanged when we move from one point to another. Their change can be expressed in terms of the same coordinate basis:
The quantities \( \Gamma^{\rho}{}_{\mu\nu} \) are the Christoffel symbols of the second kind. They are the connection coefficients associated with the chosen coordinate basis.
The Christoffel symbols depend on the coordinate system and are not tensors. They describe the connection, which is needed to compare vectors at different points and to define covariant differentiation. Spacetime curvature is instead described by the Riemann curvature tensor.
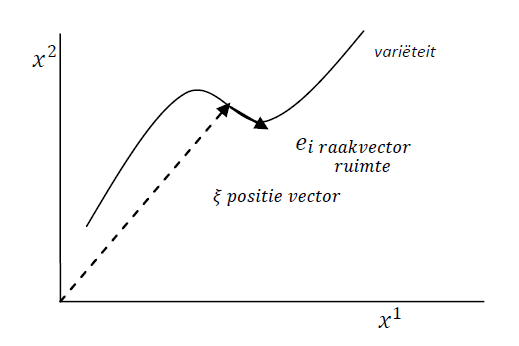
Consider a coordinate system \( x^{i} \) with an associated position vector \( \boldsymbol{\xi}(x^{i}) \), pronounced “ksi,” which represents a spatial manifold. We define the basis vectors in the tangent space as the partial derivatives of \( \boldsymbol{\xi} \):
The derivative of this basis vector with respect to another coordinate \( x^{j} \) indicates how the direction of the basis vector changes in space:
This second derivative can be expressed as a linear combination of the basis vectors themselves:
Here, \( \Gamma^{k}{}_{ij} \) is the Christoffel symbol of the second kind. Christoffel symbols describe how the coordinate basis changes from point to point and define the covariant derivative. They are not themselves tensors and do not directly represent curvature. Curvature is represented invariantly by the Riemann tensor constructed from the Christoffel symbols and their derivatives.
2.5.1.1 Ricci Curvature and Riemann Curvature
The Ricci tensor describes the part of spacetime curvature that is directly related to the local distribution of matter and energy. In vacuum,
This does not necessarily mean that spacetime is flat. The Riemann curvature tensor describes the full intrinsic curvature of spacetime and can remain non-zero even when the Ricci tensor vanishes.
For example, outside the Sun the Schwarzschild spacetime is a vacuum:
The spacetime is therefore Ricci-flat but not flat. This remaining curvature produces effects such as tidal gravitational effects, where neighbouring freely falling objects can move closer together or farther apart because their geodesics converge or diverge.
In contrast, in flat spacetime,
Thus, vacuum does not necessarily mean flat spacetime. A vacuum gravitational field can have zero Ricci curvature while the full Riemann curvature remains non-zero.
2.5.1.2 Vectorial Interpretation of Directional Change
The coordinate basis vectors \(e_{\mu}\) belong to the tangent space at each point of the manifold. The connection describes how these basis vectors are related when moving in a coordinate direction:
A nonzero Christoffel symbol does not by itself imply that spacetime is curved. Christoffel symbols may be nonzero even in flat spacetime when curvilinear coordinates are used. Curvature is determined by the Riemann curvature tensor, not by the Christoffel symbols alone.
The Riemann curvature tensor provides the invariant measure of spacetime curvature. If \(R^{\rho}{}_{\sigma\mu\nu}=0\) throughout a region, the spacetime geometry is locally flat in that region. The coordinate basis vectors and the Christoffel symbols may nevertheless vary from point to point, depending on the coordinate system.
This distinction is important for the motion of light. A light ray in a gravitational field follows a null geodesic through spacetime. The ray is freely propagating through vacuum and does not require a gravitational force in the Newtonian sense. Nevertheless, near a massive body such as the Sun, spacetime itself is curved, so the null geodesic can differ from a straight line in flat spacetime.
Thus, saying that a freely falling object or a light ray follows a geodesic does not mean that its trajectory must appear as a straight Euclidean line in every coordinate system. A geodesic is the natural generalization of straight-line motion to curved spacetime.
Written out fully, equation (\ref{eq:R251}) takes the form
We omit the vector notation for \( e_{\mu} \) for readability.
2.5.1.3 Derivation of the Christoffel Symbol
Let \(e^{\rho}\) denote the dual basis, defined by its action on the coordinate basis vectors:
Applying the dual basis covector \(e^{\rho}\) to \(\nabla_{\nu}e_{\mu}=\Gamma^{\sigma}{}_{\mu\nu}e_{\sigma}\) isolates the corresponding connection coefficient:
This provides a direct definition of the Christoffel symbol.
2.5.1.4 Symmetry of the Lower Indices
For the Levi-Civita connection, the torsion tensor vanishes. In a coordinate basis this implies symmetry of the lower indices of the Christoffel symbols:
This symmetry is therefore a consequence of the torsion-free property of the Levi-Civita connection. It should not be interpreted as a general property of every possible connection.
2.5.1.5 Coordinate Transformation View
In a coordinate transformation, Christoffel symbols arise from second derivatives of the coordinate transformation. This explains why they do not transform as tensor components. The following relation is useful for understanding this coordinate dependence.
Consider again
Substitution into (\ref{eq:R251}) yields
This expression illustrates the coordinate dependence of the Christoffel symbols. Their appearance through second derivatives of the coordinate transformation is one reason why they do not transform as tensor components.
2.5.1.6 Relation to the Metric Tensor
The metric tensor defines the inner product of tangent vectors. In a coordinate basis, its components are
The inverse metric \(g^{\mu\nu}\) satisfies
The metric provides a mapping between vectors and covectors. For a vector \(V^{\mu}\), its associated covector is
Thus, raising and lowering indices is performed using the metric and its inverse.
2.5.1.7 Summary
- The Christoffel symbol \(\Gamma^{k}{}_{ij}\) describes how basis vectors change in curved space.
- It plays a central role in the definition of the covariant derivative, which is discussed in the next section.
- The symmetry \(\Gamma^{k}{}_{ij} = \Gamma^{k}{}_{ji}\) follows from the commutativity of partial derivatives.
- The Christoffel symbol can be expressed both via coordinate derivatives and via the metric tensor, and is therefore fundamentally linked to the structure of space-time.
2.5.2 Covariant Derivative
The ordinary partial derivative of a tensor component does not, in general, transform as a tensor. The reason is that both the components of the tensor and the coordinate basis may change from point to point. The covariant derivative corrects for this coordinate dependence by including the connection coefficients.
For the Levi-Civita connection, the metric is compatible with the connection:
Together with the requirement that the connection be torsion-free, metric compatibility uniquely determines the Levi-Civita connection.
2.5.2.1 Metric and Derivatives
We start with the metric tensor (\ref{eq:R57})
Take the ordinary derivative with respect to \( x^s \):
Using the previously derived symmetry (see equation (\ref{eq:R51})), we can write:
Bringing these terms to one side of the equation, we obtain:
2.5.2.2 Definition of the Covariant Derivative
This relation motivates the definition of the covariant derivative of the metric:
We now express the tangent space derivatives in terms of Christoffel symbols. From the previous section we know:
Thus equation (\ref{eq:R61}) becomes:
Here we obtain the covariant derivative of the metric tensor, expressed in the ordinary derivative, corrected by two terms that are products of the metric tensor and the corresponding Christoffel symbol:
2.5.2.3 Cyclic Permutation
By applying the same logic to permutations of the indices, we obtain:
We now perform the following operation: (\ref{eq:R66})+(\ref{eq:R65})-(\ref{eq:R64}), taking into account the symmetry as stated in equation (\ref{eq:R51}), namely \(\Gamma^i{}_{jk} = \Gamma^i{}_{kj}\), yielding:
2.5.2.4 Christoffel Symbols from the Metric
Combining metric compatibility, \( \nabla_{\rho}g_{\mu\nu}=0 \), with the torsion-free condition \( \Gamma^{\rho}{}_{\mu\nu}=\Gamma^{\rho}{}_{\nu\mu} \), gives the unique Levi-Civita connection:
Thus, for the Levi-Civita connection, the Christoffel symbols are determined completely by the metric tensor and its first derivatives.
2.5.2.5 Remarks
2.5.2.5.1 Covariance of the Metric
We confirm that the covariant derivative of the metric is indeed zero (see equations (\ref{eq:R571}) and (\ref{eq:R572})):
Using: \(A_\mu = g_{\mu\nu} A^\nu\) and the Leibniz rule (product rule):
Both (73) and (74) must yield the same result, so:
Then: \(A^\nu \nabla_\rho g_{\mu\nu} = 0\). Since \(A^\nu \neq 0\), it follows that \(\nabla_\rho g_{\mu\nu} = 0\).
From this it follows that the covariant derivative of the metric is zero, which is a fundamental property of the Levi-Civita connection.
2.5.2.5.2 Transformation Rule of Vector Components
Consider a vector: \(\mathbf{V} = V^{\nu} \mathbf{e}_{\nu}\).
The component in the direction of the \({\mu}\)-axis is:
As we know: \(g_{\mu\nu} = \mathbf{e}_{\mu} \cdot \mathbf{e}_{\nu} = g_{\nu\mu}\). Thus:
Conversely, using the inverse metric \(g^{\mu\nu}\), we recover the contravariant components:
The metric and its inverse satisfy
Thus, lowering and raising an index are inverse operations. The metric tensor maps a contravariant vector to its corresponding covector, while the inverse metric maps the covector back to the contravariant vector.
2.5.2.6 Covariant Derivative of a Contravariant Vector
We now want to compute the covariant derivative of a contravariant vector field \(V^{\mu}\). In flat space, this would simply be the ordinary partial derivative. In curved space-time, however, we must take into account that the basis vectors themselves may vary from point to point.
2.5.2.6.1 Starting Point: Vector in Component Form
We consider a contravariant vector \(\mathbf{V}\) written as a linear combination of the basis vectors \(\mathbf{e}_{\mu}\):
Here, \(\mathbf{V}\) denotes the complete vector, while \(V^{\mu}\) denotes its contravariant components. The quantities \(V^{\mu}\) are scalar component functions of the coordinates \(x^{\nu}\), whereas \(\mathbf{e}_{\mu}\) are the basis vectors. Thus, \(V^{\mu}\) by itself is not the vector; it is the coefficient multiplying the basis vector \(\mathbf{e}_{\mu}\).
When the vector is described in a curved or non-Cartesian coordinate system, both its components \(V^{\mu}\) and the basis vectors \(\mathbf{e}_{\mu}\) may change from one point to another. Therefore, when we differentiate the complete vector \(\mathbf{V}\) with respect to a coordinate \(x^{\nu}\), we must differentiate both the components and the basis vectors. Applying the product rule gives:
The first term describes how the component functions \(V^{\mu}\) change, while the second term describes how the basis vectors \(\mathbf{e}_{\mu}\) change. This distinction is essential: the ordinary partial derivative accounts for the change of the component functions, but it does not by itself account for the change of the coordinate basis.
2.5.2.6.2 Connection with the Christoffel Symbol
From earlier work (equation (\ref{eq:R251})), we know that the covariant derivative of a basis vector is expressed in terms of the Christoffel symbols:
We now apply this relation to the contravariant vector \(\mathbf{A}=A^{\mu}\mathbf{e}_{\mu}\). Here \(\mathbf{A}\) is the complete vector, while \(A^{\mu}\) are its scalar component functions.
Taking the covariant derivative of the complete vector and applying the product rule gives:
The ordinary partial derivative appears here because \(A^{\mu}\), considered by itself, is a scalar component function. The second term is required because the basis vectors \(\mathbf{e}_{\mu}\) themselves change from point to point.
Substituting the expression for the covariant derivative of the basis vector gives:
We may now rename the dummy index \(\mu\) in the first term to \(\rho\), so that both terms are expressed using the same basis vector:
Since the basis vectors \(\mathbf{e}_{\rho}\) are linearly independent, the quantity multiplying \(\mathbf{e}_{\rho}\) is the corresponding component of the covariant derivative. Therefore:
This is the covariant derivative of the contravariant vector components. The first term describes the change of the component functions \(A^{\rho}\), while the Christoffel-symbol term accounts for the change of the coordinate basis.
2.5.2.6.3 Definition of the Covariant Derivative
This directly yields the definition of the covariant derivative of the contravariant vector \(\mathbf{V}\), expressed in terms of its components \(V^{\mu}\):
The extra term involving the Christoffel symbol accounts for the fact that the basis vectors themselves change from point to point. The first term describes the change of the component function \(V^{\mu}\), while the second term accounts for the change of the coordinate basis. Together, these terms form the covariant derivative, whose components transform tensorially under coordinate transformations.
2.5.2.6.4 Note: Dummy Indices
In Einstein notation, a repeated index that is summed over is called a dummy index. Its name can be changed without changing the meaning of the expression, provided that the index is changed consistently within its contraction.
For example:
The dummy index \(\mu\) could equally well be replaced by another index, such as \(\rho\) or \(k\):
The result is unchanged because the index is only a placeholder for the summation over the four spacetime dimensions.
2.5.2.6.5 Summary
-
The covariant derivative of a contravariant vector \(V^{\mu}\) is:
\begin{align} \nabla_{\nu}V^{\mu} = \frac{\partial V^{\mu}}{\partial x^{\nu}} + \Gamma^{\mu}{}_{\nu\rho}V^{\rho}. \label{eq:R80} \end{align}
- The covariant derivative extends the ordinary partial derivative by adding a connection term. This term accounts for the fact that the coordinate basis vectors may vary from point to point. The Christoffel symbols describe this connection, but they do not themselves represent spacetime curvature.
- The covariant derivative \(\nabla_{\nu}V^{\mu}\) is a tensor of rank 2 (type \((1,1)\)): it has one contravariant index \(\mu\) and one covariant index \(\nu\).
2.5.2.7 Covariant Derivative of a Covariant Vector
We now examine how the covariant derivative acts on a covector \(B_\mu\). We make use of the scalar product of a contravariant vector \(A^\mu\) and a covector \(B_\mu\), and then apply the differentiation rules.
2.5.2.7.1 Starting Point: Product Rule on a Scalar Quantity
Consider the scalar product
Because the contraction of a contravariant vector with a covector produces a scalar, its covariant derivative is equal to its ordinary partial derivative:
Applying the product rule to the covariant derivative gives:
From the previous section, the covariant derivative of the contravariant vector \(A^\mu\) is:
Substituting this expression gives:
2.5.2.7.2 Property of Scalars
Since the scalar product \(A^\mu B_\mu\) is a scalar, its covariant derivative is equal to its ordinary partial derivative:
2.5.2.7.3 Comparison of Both Expressions
Equations (\ref{eq:R87}) and (\ref{eq:R88}) describe the same scalar quantity. Therefore, their right-hand sides must be equal:
Expanding the right-hand side and cancelling the common term \(\frac{\partial A^\mu}{\partial x^\alpha}B_\mu\), we obtain:
In the first term on the right-hand side, \(\mu\) and \(\nu\) are dummy indices. We may therefore rename them as \(\mu\rightarrow\sigma\) and \(\nu\rightarrow\mu\):
Bringing all terms to one side gives:
Since this relation must hold for an arbitrary vector \(A^\mu\), the expression in parentheses must vanish. Therefore:
This is the covariant derivative of a covariant vector, also called a covector. Notice the minus sign in front of the Christoffel term. It is the opposite of the corresponding term for a contravariant vector:
2.5.2.7.4 Definition
This is the covariant derivative of a covariant vector \(B_\mu\), also called a covector. The formula is analogous to that for a contravariant vector, but the Christoffel term appears with a minus sign:
-
For a contravariant vector \(V^\mu\):
\begin{align} \nabla_\alpha V^\mu = \frac{\partial V^\mu}{\partial x^\alpha} + \Gamma^\mu{}_{\alpha\nu}V^\nu \end{align}
-
For a covariant vector \(B_\mu\), also called a covector:
\begin{align} \nabla_\alpha B_\mu = \frac{\partial B_\mu}{\partial x^\alpha} - \Gamma^\sigma{}_{\alpha\mu}B_\sigma \end{align}
The opposite signs reflect the different transformation properties of contravariant and covariant components.
2.5.2.7.5 Summary
-
The covariant derivative of a covector \(B_\mu\) is:
\begin{align} \nabla_\alpha B_\mu = \frac{\partial B_\mu}{\partial x^\alpha} - \Gamma^\sigma{}_{\alpha\mu}B_\sigma. \end{align}
- The Christoffel term accounts for the effect of the connection on the covector components and compensates for the variation of the coordinate basis.
- This definition ensures that the covariant derivative transforms as a tensor.
2.5.3 Relation to Tensors
In this section, we investigate how the ordinary derivative of a covector \(V_\mu\) behaves under a coordinate transformation. We will see that the ordinary derivative of a covector does not, in general, transform as a rank-2 tensor. This is why the covariant derivative is required to obtain a tensorial quantity.
2.5.3.1 Transformation of a Derivative
Consider the array of partial derivatives in the \(x\)-coordinate system:
In another coordinate system \(y^\alpha\), the corresponding partial derivatives are
We now investigate whether these partial derivatives transform according to the tensor transformation law. If they did, \(T_{\mu\nu}\) would be a rank-2 covariant tensor. The calculation below will show that an additional term appears under a general coordinate transformation.
2.5.3.2 Expected Tensor Transformation
If \(T_{\mu\nu}\) were a rank-2 covariant tensor, its components in the \(y\)-coordinate system would have to transform according to
If we temporarily identify \(T_{\mu\nu}(x)\) with the ordinary derivative \(\partial_\nu V_\mu(x)\), this would imply
Using the chain rule for the derivative with respect to \(y^\beta\),
we obtain the expression that the tensor transformation law would require:
We now compare this with the actual ordinary derivative of the transformed covector \(V_\alpha(y)\). Since a covector transforms as
differentiating with respect to \(y^\beta\) gives
The first term is an additional term involving the second derivative of the coordinate transformation. Therefore,
in general. This extra term is precisely why the ordinary derivative of a covector does not transform as a rank-2 tensor.
2.5.3.3 Calculation of \(\frac{\partial V_\alpha(y)}{\partial y^\beta}\)
The covector components transform according to
Differentiate both sides with respect to \(y^\beta\):
Applying the product rule gives
We now express \(V_\mu(x)\) in terms of the covector components in the \(y\)-coordinate system. Using the inverse transformation,
Substituting this into equation (\ref{eq:R99}) gives
The second term contains the second derivative of the coordinate transformation. This is the additional term that prevents the ordinary derivative of a covector from transforming as a rank-2 tensor.
2.5.3.4 Relation to Christoffel Symbols
Recall the relation between the second derivative of the coordinate transformation and the Christoffel symbols:
Using this relation, the second term in equation (\ref{eq:R101}) can be written as
Therefore, equation (\ref{eq:R101}) becomes
Rearranging gives
The expression on the right-hand side is precisely the covariant derivative of the covector \(V_\alpha\):
Thus, unlike the ordinary partial derivative, the covariant derivative transforms as a rank-2 covariant tensor.
2.5.3.5 Covariant Derivative of \(V_\alpha\)
From the result obtained above, we have
The expression on the right-hand side is precisely the covariant derivative of the covector \(V_\alpha\), as derived in §2.5.2.7.4. Therefore,
Thus, the combination of the ordinary derivative and the Christoffel term transforms as a rank-2 covariant tensor, whereas the ordinary derivative \(\partial_\beta V_\alpha\) does not.
2.5.3.6 Conclusion
-
The ordinary derivative
\begin{align} \frac{\partial V_\alpha}{\partial x^\beta} \end{align}is not, in general, a tensor.
- An additional connection term involving the Christoffel symbols is required to obtain a tensorial quantity.
-
The resulting tensorial quantity is the covariant derivative:
\begin{align} T_{\alpha\beta} = \nabla_\beta V_\alpha = \frac{\partial V_\alpha}{\partial x^\beta} - \Gamma^\sigma{}_{\beta\alpha}V_\sigma. \end{align}
2.5.3.7 Covariant Differentiation of a Covariant Tensor
2.5.3.7.1 Starting Point
Consider a rank-2 covariant tensor \(T_{\mu\nu}\) constructed as the tensor product of two covectors \(A_\mu\) and \(B_\nu\):
We now take the covariant derivative of this tensor with respect to \(x^\alpha\):
The covariant derivative obeys the product rule:
Using the definition of the covariant derivative of a covector (see §2.5.2.7),
Substituting these expressions into equation (\ref{eq:R112}) gives
Expanding the products, we obtain
The first two terms combine according to the ordinary product rule:
2.5.3.7.2 Final Formula
Since \(T_{\mu\nu}=A_\mu B_\nu\), the result obtained above can be written directly in terms of the tensor components:
This is the covariant derivative of a rank-2 covariant tensor. Each covariant index contributes one Christoffel term.
2.5.3.7.3 Summary
The covariant derivative of a rank-2 covariant tensor \(T_{\mu\nu}\) consists of:
- the ordinary derivative \(\frac{\partial T_{\mu\nu}}{\partial x^\alpha}\),
- one Christoffel correction term for the covariant index \(\mu\),
- and one Christoffel correction term for the covariant index \(\nu\).
Thus,
The resulting quantity \(\nabla_\alpha T_{\mu\nu}\) is a rank-3 covariant tensor and therefore transforms tensorially under a coordinate transformation.
2.5.3.8 Covariant Differentiation of a Contravariant Tensor
We now extend the concept of covariant differentiation to a rank-2 contravariant tensor. Such a tensor has two upper indices. We again use the product rule together with the covariant derivative of a contravariant vector.
2.5.3.8.1 Starting Point
Consider a rank-2 contravariant tensor \(T^{\mu\nu}\) constructed as the tensor product of two contravariant vectors:
The covariant derivative of \(T^{\mu\nu}\) with respect to \(x^\alpha\) obeys the product rule:
Using the covariant derivative of a contravariant vector (see §2.5.2.6.3),
Substituting these expressions into the product rule gives
Expanding the products, we obtain
The first two terms combine according to the ordinary product rule:
2.5.3.8.2 Final Formula
Since \(T^{\mu\nu}=A^\mu B^\nu\), the result obtained above can be written directly in terms of the tensor components:
This is the covariant derivative of a rank-2 contravariant tensor. Each contravariant index contributes one Christoffel term with a positive sign.
2.5.3.8.3 Summary
The covariant derivative of a rank-2 contravariant tensor \(T^{\mu\nu}\) consists of:
- the ordinary derivative \(\frac{\partial T^{\mu\nu}}{\partial x^\alpha}\),
- one Christoffel correction term for the contravariant index \(\mu\),
- and one Christoffel correction term for the contravariant index \(\nu\).
Thus, each upper index contributes a Christoffel term with a positive sign. In \(\Gamma^\mu{}_{\alpha\beta}\), the upper index \(\mu\) identifies the tensor index being differentiated, \(\alpha\) is the differentiation index, and \(\beta\) is the summed index.
2.5.3.9 Covariant Differentiation of a Mixed Tensor
We now consider how the covariant derivative is applied to a mixed tensor, a tensor that has both contravariant and covariant indices.
2.5.3.9.1 Starting Point
Consider the mixed tensor \(T^\mu{}_\nu\), defined as the product of a contravariant vector \(A^\mu\) and a covariant vector \(B_\nu\):
The covariant derivative of \(T^\mu{}_\nu\) with respect to \(x^\alpha\) is:
2.5.3.9.2 Use of Covariant Derivatives
We now substitute the known expressions for the covariant derivatives of a contravariant vector and a covector:
Substituting these expressions into equation (\ref{eq:R125}) gives
Expanding the products, we obtain
The first two terms combine according to the ordinary product rule:
2.5.3.9.3 Final Formula
Since \(T^\mu{}_\nu=A^\mu B_\nu\), the result can be written directly in terms of the mixed tensor components:
The first Christoffel term corresponds to the contravariant index \(\mu\) and therefore has a positive sign. The second corresponds to the covariant index \(\nu\) and therefore has a negative sign.
2.5.3.10 General Rule for Tensor Covariant Derivatives
The pattern becomes clear from the preceding examples. For every upper index, one Christoffel-symbol term with a positive sign is added. For every lower index, one Christoffel-symbol term with a negative sign is added.
Here, \(\rho\) is a dummy index and is summed over. In the first sum, \(\rho\) replaces the upper index \(\mu_i\); in the second sum, \(\rho\) replaces the lower index \(\nu_j\).
This rule applies to tensors of arbitrary rank and provides the general definition of the covariant derivative of a tensor.
2.5.4 Key Points and Intuition
- Christoffel symbols \( \Gamma^{\mu}{}_{\nu\rho} \) are the connection coefficients associated with a coordinate basis.
- Christoffel symbols are not tensors. They may be nonzero even in flat spacetime when curvilinear coordinates are used.
- The covariant derivative combines the ordinary derivative with connection terms so that the result transforms tensorially.
- For the Levi-Civita connection, the connection is torsion-free and metric-compatible: \( \Gamma^{\mu}{}_{\nu\rho}=\Gamma^{\mu}{}_{\rho\nu} \) and \( \nabla_{\lambda}g_{\mu\nu}=0 \).
- The Christoffel symbols describe the connection; spacetime curvature is determined by the Riemann curvature tensor.
Intuitive
Imagine walking on a sphere while carrying an arrow and attempting to keep it parallel to itself as you move. Because the coordinate basis changes from point to point, ordinary derivatives alone are not sufficient to describe the change of the arrow. The connection, represented in a coordinate basis by the Christoffel symbols, provides the correction needed to define parallel transport.
The important distinction is that the connection describes how vectors are compared and transported, whereas curvature is an intrinsic property of the geometry. The Christoffel symbols describe the connection and enter directly into the calculation of the Riemann curvature tensor. However, the Christoffel symbols themselves are not a measure of intrinsic curvature, because they can be made to vanish at a point by a suitable choice of coordinates. The Riemann tensor, by contrast, is a tensorial measure of spacetime curvature.
Summary overview:
| Concept | Meaning |
|---|---|
| \(\Gamma^{\rho}{}_{\mu\nu}\) | Connection coefficients associated with a coordinate basis |
| Covariant derivative | Derivative that accounts for the connection and transforms tensorially |
| \(\nabla_{\nu}V^{\mu}\) | \(\partial_{\nu}V^{\mu} +\Gamma^{\mu}{}_{\nu\rho}V^{\rho}\) |
| Parallel transport | Comparison and transport of vectors using the connection |
| Riemann tensor | Tensor describing the intrinsic curvature of spacetime |
2.6 Geodesic Equation and Christoffel Symbols
As discussed earlier, Einstein formulated gravity geometrically: a freely falling object is not regarded as being acted upon by a gravitational force in the Newtonian sense, but follows a natural path determined by the geometry of space-time. Such a path is called a geodesic.
In a local freely falling coordinate system \(\xi^\alpha\), the motion of a freely falling object can be described, at the point under consideration, by
Here, \(\tau\) is the proper time measured along the worldline of the freely falling object. The local freely falling coordinates are chosen so that, at the point under consideration, the effects associated with the connection can be eliminated. In such a local inertial frame, the geodesic therefore has the form of a straight worldline.
In a general coordinate system, however, the same worldline need not have zero coordinate acceleration. The transformation from the local coordinates \(\xi^\alpha\) to general coordinates \(x^\mu\) introduces the connection coefficients, or Christoffel symbols. This leads to the general geodesic equation developed below.
2.6.1 Explanation of Terms
2.6.1.1 Local (Freely Falling) Frame \(\xi^\alpha\)
This is a coordinate system defined locally in space-time and chosen so that, at the point under consideration, a freely falling observer behaves like an inertial observer. At that point, the Christoffel symbols can be made to vanish, and the laws of physics take their locally inertial form. This does not mean that space-time is globally flat or that its curvature vanishes.
2.6.1.2 General Coordinate System \(x^\mu\)
This denotes a general coordinate system used to describe points in space-time. The coordinates \(x^\mu\) need not correspond to a freely falling frame and may be chosen according to the symmetry or physical problem being considered. In a curved space-time, the Christoffel symbols generally do not vanish throughout such a coordinate system.
2.6.1.3 The Relation Between the Two
The local freely falling coordinates \(\xi^\alpha\) and the general coordinates \(x^\mu\) are related by a coordinate transformation. At a given point, the transformation can be chosen so that the local coordinates form an inertial frame. The corresponding coordinate acceleration vanishes there, while the same worldline expressed in general coordinates acquires the connection terms represented by the Christoffel symbols.
2.6.1.4 Meaning in Physics
In general relativity, one can choose, at any given point, a locally inertial coordinate system in which the Christoffel symbols vanish at that point. In this local freely falling frame, the laws of physics take the same form as in a special-relativistic inertial frame.
This does not mean that the space-time curvature vanishes. The Christoffel symbols can be made to vanish at a point by a suitable choice of coordinates, whereas the Riemann curvature tensor cannot generally be eliminated in this way. Thus, a freely falling observer can locally eliminate the effects of the connection, but not genuine space-time curvature.
2.6.1.5 Derivation via Coordinate Transformation
Let \(\xi^\alpha\) be the coordinates in the local freely falling frame, while \(x^\mu\) are coordinates in a general coordinate system. The two coordinate systems are related by a general coordinate transformation:
Along the worldline of the freely falling object, the first derivative is
Differentiating once more with respect to proper time gives
Applying the chain rule to the first term,
In the local freely falling frame, the freely falling object satisfies
Therefore,
To express the result in the \(x^\mu\) coordinates, multiply by the inverse Jacobian \(\frac{\partial x^\beta}{\partial\xi^\alpha}\):
Using the inverse-Jacobian relation
we obtain
The coefficient multiplying the two velocity components is identified with the Christoffel symbol:
Substitution gives the geodesic equation:
2.6.2 Result and Interpretation
The coordinate transformation from the local freely falling frame to a general coordinate system introduces the Christoffel symbols. The geodesic equation is therefore
The first term represents the ordinary coordinate acceleration, while the second term accounts for the connection associated with the chosen coordinate system. Their combination vanishes for a freely falling particle following a geodesic.
It is important not to interpret the Christoffel symbols themselves as spacetime curvature. They describe the connection and depend on the choice of coordinates. They can therefore be nonzero even in flat spacetime, for example when curvilinear coordinates are used.
In a local freely falling coordinate system at a given point, the Christoffel symbols can be chosen to vanish at that point. The geodesic equation then reduces locally to
Thus, a freely falling object follows a straight worldline locally in its freely falling frame. In a general coordinate system, the same worldline may have nonzero coordinate acceleration because of the connection terms.
The relation derived above can be written as
For a freely falling particle, the left-hand side vanishes, giving
Equivalently,
This equation does not describe a gravitational force in the Newtonian sense. Rather, it expresses how the coordinate description of a geodesic depends on the connection associated with the chosen coordinates.
Remark 1: Affine Parameter
For a massless particle following a null worldline, proper time cannot be used as a parameter along the trajectory. Instead, an affine parameter \(\lambda\) can be introduced. The geodesic equation then takes the form
An affine parameter is chosen so that the geodesic equation retains this simple form. Its numerical normalization is arbitrary.
Remark 2: Speed of Light \(c\)
In much of the literature, \(c=1\) is chosen for simplicity. In this document, however, the speed of light \(c\) is kept explicit where appropriate. This makes dimensional analysis more transparent.
2.6.3 Key Points and Intuition
- Geodesics are the straightest possible worldlines in curved spacetime. They generalize the straight-line motion of inertial particles in special relativity.
- In general relativity, a freely falling particle with no non-gravitational forces follows a geodesic.
-
The geodesic equation is
\begin{align} \frac{d^2 x^\mu}{d\tau^2} + \Gamma^\mu{}_{\nu\rho} \frac{dx^\nu}{d\tau} \frac{dx^\rho}{d\tau} = 0. \end{align}
- The Christoffel symbols describe the connection associated with the chosen coordinates. They are not themselves a tensor and are not, by themselves, a measure of spacetime curvature.
- Genuine spacetime curvature is described by the Riemann curvature tensor. It can remain nonzero even when the Christoffel symbols vanish at a particular point.
Intuitive
Imagine an object moving freely on the surface of a sphere. If the object is constrained to remain on the surface, its geodesic is a great circle: the straightest possible path within the geometry of the surface.
In spacetime, a freely falling object similarly follows a geodesic. An observer falling together with the object does not detect a gravitational force locally. In the observer's local inertial coordinates, the worldline is locally straight.
An observer using a general coordinate system may nevertheless describe the same worldline as having nonzero coordinate acceleration. The Christoffel symbols account for this coordinate-dependent description of the connection. They should therefore not be confused with the Riemann curvature itself.
Table overview:
| Quantity | Meaning |
|---|---|
| \(x^\mu(\tau)\) | Coordinates of a timelike particle as a function of proper time |
| \(\frac{d^2 x^\mu}{d\tau^2}\) | Coordinate acceleration along the worldline |
| \(\Gamma^\mu{}_{\nu\rho}\) | Connection coefficients associated with the chosen coordinates |
| Geodesic equation | Equation describing force-free motion along a geodesic |
| Riemann tensor | Tensor describing the intrinsic curvature of spacetime |
2.7 Christoffel Symbols Expressed in Terms of the Metric Tensor
As discussed earlier, the metric tensor \(g_{\mu\nu}\) contains all information about the curvature and geometry of space-time. In this section, we will show how the Christoffel symbol \(\Gamma^\beta{}_{\mu\nu}\) can be expressed entirely in terms of the metric tensor and its derivatives.
2.7.1 Conditions and Definitions
We start from the following standard forms:
- Metric tensor (from local flat space):
\begin{align} g_{\mu\nu} = \eta_{\alpha\beta} \frac{\partial \xi^\alpha}{\partial x^\mu} \frac{\partial \xi^\beta}{\partial x^\nu} \end{align}where \(\eta_{\alpha\beta} = \text{diag}(1,-1,-1,-1)\) is the Minkowski metric (see also Chapter 5.6.1).
- Christoffel symbol (via transformation):
\begin{align} \Gamma^\beta{}_{\mu\nu} = \frac{\partial x^\beta}{\partial \xi^\lambda} \frac{\partial^2 \xi^\lambda}{\partial x^\mu \partial x^\nu} \end{align}
Important: The transformation relation above is evaluated with respect to a local inertial coordinate system \(\xi^\alpha\), in which the Christoffel symbols vanish at the point under consideration. It therefore expresses how the connection coefficients arise in the general coordinates \(x^\mu\).
2.7.2 Derivation via the Chain Rule
We start from the metric expressed in terms of the locally flat coordinates \(\xi^\alpha\):
Since the metric tensor is symmetric, \(g_{\mu\nu}=g_{\nu\mu}\). We therefore need the following three cyclic forms:
Similarly, by cyclic permutation of the free indices:
We now relate the second derivatives of the local coordinates \(\xi^\alpha\) to the Christoffel symbols. From the transformation relation
multiply by \(\partial \xi^\sigma/\partial x^\beta\):
Using the chain rule,
where \(\delta^\sigma{}_\lambda\) is the Kronecker delta. Therefore:
Hence:
Applying this relation to the second derivatives appearing in (\ref{eq:R152}) gives:
From the definition of the metric,
and similarly,
Therefore:
The two other cyclic permutations are:
Now form (\ref{eq:R163}) + (\ref{eq:R164}) - (\ref{eq:R165}). For the Levi-Civita connection, \(\Gamma^\rho{}_{\mu\nu}=\Gamma^\rho{}_{\nu\mu}\). Using this symmetry, the terms combine to give:
Multiplying by the inverse metric \(g^{\beta\alpha}\) gives:
This is the standard expression for the Christoffel symbols of the Levi-Civita connection in terms of the metric tensor.
In compact notation, where \(g_{\alpha\mu,\nu}\equiv\partial_\nu g_{\alpha\mu}\), this becomes:
2.7.3 Summary
The Christoffel symbols are fully expressed in terms of the metric tensor \(g_{\mu\nu}\) and its first derivatives:
Or in short notation:
2.7.4 Key Points and Intuition
- For the Levi-Civita connection, the Christoffel symbols \(\Gamma^\lambda{}_{\mu\nu}\) are completely determined by the metric tensor \(g_{\mu\nu}\) and its first derivatives.
-
The explicit formula is:
\begin{align} \Gamma^\lambda{}_{\mu\nu} = \frac{1}{2}g^{\lambda\rho} \left( \partial_\mu g_{\rho\nu} + \partial_\nu g_{\rho\mu} - \partial_\rho g_{\mu\nu} \right). \end{align}
- The Christoffel symbols are the connection coefficients associated with the chosen coordinate basis. They enter the covariant derivative and determine how vectors are compared and transported from one point to another.
- The Christoffel symbols are not themselves a measure of spacetime curvature. They can be nonzero even in flat spacetime when curvilinear coordinates are used.
-
For the Levi-Civita connection, the lower indices are symmetric:
\begin{align} \Gamma^\lambda{}_{\mu\nu} = \Gamma^\lambda{}_{\nu\mu}. \end{align}This follows from the torsion-free property of the connection.
- The metric and its derivatives determine the Levi-Civita connection, while the connection and its derivatives determine the Riemann curvature tensor.
Intuitive
The metric tensor \(g_{\mu\nu}\) tells us how spacetime intervals, distances and angles are measured at each point.
When we move from one point to another, the coordinate basis may change. The connection describes how vectors are compared and transported between different points. In a coordinate basis, this connection is represented by the Christoffel symbols \(\Gamma^\lambda{}_{\mu\nu}\).
This also explains why the Christoffel symbols themselves cannot be identified with curvature. Their values depend on the coordinate system. In particular, they can be made to vanish at a chosen point by using a locally inertial coordinate system, even when the spacetime has genuine curvature.
Genuine spacetime curvature is instead described by the Riemann curvature tensor. Unlike the Christoffel symbols, the Riemann tensor cannot in general be made to vanish throughout a curved region by a coordinate transformation.
The conceptual relation can therefore be summarized as:
The metric determines the Levi-Civita connection. The Riemann tensor is then constructed from derivatives of the connection together with terms quadratic in the connection coefficients.
Table overview:
| Quantity | Meaning |
|---|---|
| \(g_{\mu\nu}\) | Metric tensor; determines how spacetime intervals and angles are measured |
| \(\partial_\sigma g_{\mu\nu}\) | Variation of the metric from point to point |
| \(\Gamma^\lambda{}_{\mu\nu}\) | Connection coefficients associated with the chosen coordinate basis |
| Covariant derivative | Derivative that accounts for the connection and transforms tensorially |
| \(R^\rho{}_{\sigma\mu\nu}\) | Riemann curvature tensor; describes the intrinsic curvature of spacetime |
2.8 Geodesic Equation and its Newtonian Limit
Newtonian gravity describes how matter generates a gravitational potential \(\Phi\), and how this potential determines the acceleration of a particle:
Here \(\Phi\) is the Newtonian gravitational potential. In Cartesian coordinates, the Euclidean gradient is
Here \(\mathbf{e}_x,\mathbf{e}_y,\mathbf{e}_z\) are the unit vectors along the respective spatial axes.
General relativity must reproduce this Newtonian description in the appropriate limit. We will now show that the geodesic equation reduces to the Newtonian equation of motion when the gravitational field is weak, static, and the particle moves slowly compared with the speed of light.
2.8.1 Assumptions for the Newtonian Limit
To obtain the Newtonian limit, we make three main assumptions:
- The particle moves slowly compared with the speed of light: \(v\ll c\).
- The gravitational field is weak, so that spacetime differs only slightly from Minkowski spacetime.
- The gravitational field is static, so that the metric does not explicitly depend on time.
2.8.2 Starting Point: the Geodesic Equation
The geodesic equation describes the worldline of a freely falling particle. Using proper time \(\tau\) as the parameter of the worldline, it is
The repeated indices \(\mu\) and \(\nu\) are summed over all four spacetime coordinates. Thus, the second term contains contributions from all combinations of temporal and spatial components.
Because the particle moves slowly compared with the speed of light, the temporal component of its four-velocity is much larger than its spatial components. We use
We use the coordinate convention
Therefore,
In the slow-motion limit, the dominant contribution to the spatial geodesic equation comes from the term with \(\mu=\nu=0\). Thus, for \(\beta=i\), we obtain the approximation
Using \(x^0=ct\), this becomes
2.8.3 Approximation of the Christoffel Symbol
The Christoffel symbols are determined by the metric tensor:
For the spatial component \(\Gamma^i{}_{00}\), we set \(\beta=i\) and \(\mu=\nu=0\):
Since the first two terms are identical,
In the static limit, the metric does not explicitly depend on the time coordinate \(x^0\). Therefore,
The first term therefore vanishes:
We are left with
Thus, in a static gravitational field, the spatial Christoffel symbol \(\Gamma^i{}_{00}\) is determined by the spatial variation of the time-time component \(g_{00}\) of the metric.
2.8.4 Weak-Field Approximation
We now impose the weak-field approximation. Spacetime is assumed to differ only slightly from flat Minkowski spacetime. We therefore write
Here \(h_{\mu\nu}\) represents the small perturbation of the metric away from Minkowski spacetime.
We use the convention
2.8.4.1 The \(00\)-Component of the Metric
The component of the metric that is relevant for the Newtonian limit is \(g_{00}\). From the weak-field decomposition,
Because \(\eta_{00}=1\) is constant,
Consequently,
Thus, to first order in the weak-field perturbation, the spatial variation of \(g_{00}\) is determined entirely by \(h_{00}\).
2.8.4.2 Approximation of \(\Gamma^i{}_{00}\)
Substituting equation (\ref{eq:R192}) into equation (\ref{eq:R1881}) gives
The inverse metric also has a weak-field expansion:
Since \(h_{\mu\nu}\) is already a small quantity, replacing \(g^{ij}\) by \(\eta^{ij}\) introduces only higher-order corrections. Therefore,
For the spatial components of the Minkowski metric with signature \((+---)\),
Hence,
The Kronecker delta selects the corresponding spatial component, so
2.8.5 Substitution into the Geodesic Equation
The spatial geodesic equation from Section 2.8.2 is
Because \(x^0=ct\),
Therefore,
Using \(\Gamma^i{}_{00} = \frac{1}{2} \frac{\partial h_{00}}{\partial x^i}\), we obtain
2.8.5.1 Switching from Proper Time to Coordinate Time
We now express the spatial acceleration in terms of the ordinary coordinate time \(t\). Using the chain rule,
Differentiating once more with respect to \(\tau\) gives
In the Newtonian limit, the time component of the geodesic equation gives
Consequently,
Substituting this result into equation (\ref{eq:R195}) gives
For a timelike particle, \(dt/d\tau\neq0\), so this common factor can be cancelled:
In general:
2.8.6 Identification with the Newtonian Potential
In Newtonian gravity, the acceleration is determined by the gravitational potential \(\Phi\):
Comparing this with equation (\ref{eq:R201}),
we find
Therefore, up to an irrelevant additive constant in the potential,
Since \(g_{00}=\eta_{00}+h_{00}\) and \(\eta_{00}=1\), we obtain
This is the central result of the Newtonian limit: the Newtonian gravitational potential is encoded in the \(00\)-component of the spacetime metric.
2.8.7 Metric Component in Terms of the Potential
The weak-field relation can therefore be summarized as
For an attractive Newtonian gravitational field generated by a spherical mass \(M\),
Thus,
This is the weak-field form of the time-time component of the Schwarzschild metric.
2.8.8 Example: Calculation of \(h_{00}\) on Earth
At the Earth's surface, the Newtonian gravitational potential is
Using \(h_{00}=2\Phi/c^2\), we obtain
Using the approximate values
- \(G=6.67\times10^{-11}\, \mathrm{m^3\,kg^{-1}\,s^{-2}}\),
- \(M_{\text{Earth}}\simeq6\times10^{24}\,\mathrm{kg}\),
- \(R_{\text{Earth}}\simeq6.4\times10^6\,\mathrm{m}\),
- \(c\simeq3\times10^8\,\mathrm{m\,s^{-1}}\),
we find
Therefore,
This confirms quantitatively that the gravitational field at the Earth's surface is weak in the sense required by the weak-field approximation.
For the Sun this is ~\(10^{-6}\) and for a white dwarf ~\(10^{-4}\), confirming that the weak-field approximation is generally valid in many realistic situations.
2.8.9 Key Points and Intuition
The Newtonian equation of motion is recovered from the relativistic geodesic equation in the weak-field, static, slow-motion limit:
The corresponding relation between the Newtonian potential and the metric perturbation is
The relevant Christoffel symbol is therefore
Substitution into the spatial geodesic equation gives
Key Points
- A freely falling particle follows a geodesic in general relativity.
- In the slow-motion limit, the temporal component of the four-velocity dominates over the spatial components.
- In a static gravitational field, the relevant connection component is approximately \(\Gamma^i{}_{00}\).
- In the weak-field approximation, \(g_{\mu\nu}=\eta_{\mu\nu}+h_{\mu\nu}\) with \(|h_{\mu\nu}|\ll1\).
- The Newtonian potential is related to the metric by \(h_{00}=2\Phi/c^2\).
- Consequently, \(g_{00}=1+2\Phi/c^2\).
- Substitution into the geodesic equation reproduces \(d^2x^i/dt^2=-\partial\Phi/\partial x^i\).
Intuition
The Newtonian gravitational potential is not introduced as a separate force law in general relativity. In the weak-field limit, it is encoded in the \(00\)-component of the spacetime metric.
The chain of ideas is therefore
In words:
- the metric describes the geometry of spacetime;
- the weak-field perturbation \(h_{00}\) contains the Newtonian gravitational potential;
- derivatives of the metric determine the Christoffel symbols;
- the Christoffel symbols determine the geodesic motion;
- in the Newtonian limit, that geodesic motion becomes the familiar Newtonian acceleration.
Summary Comparison Table
| Theory | Formula | Interpretation |
|---|---|---|
| Newtonian gravity | \(\mathbf{a}=-\nabla\Phi\) | Acceleration determined by the gravitational potential |
| General relativity | \(\displaystyle \frac{d^2x^i}{dt^2} = -c^2\Gamma^i{}_{00} \) | Spatial acceleration obtained from the geodesic equation |
| Weak-field connection | \(\displaystyle \Gamma^i{}_{00} \approx \frac{1}{c^2} \frac{\partial\Phi}{\partial x^i} \) | The metric determines the connection, which reproduces the Newtonian acceleration |
| Metric-potential relation | \(\displaystyle g_{00} \approx 1+\frac{2\Phi}{c^2} \) | The Newtonian potential is encoded in the time-time component of the metric |
2.9 Generalizing the Definition of the Metric Tensor
In the previous sections, we have seen how the geodesic equation can be written in arbitrary coordinate systems. We now make a similar generalization for the metric tensor.
We begin with the Minkowski metric in a local inertial frame and then transform the coordinates to a general coordinate system. This shows how the metric components change under a coordinate transformation and motivates the general definition of the metric tensor \(g_{\mu\nu}\) used in general relativity.
The resulting spacetime can be described mathematically as a pseudo-Riemannian manifold. In general coordinates, the metric components may vary from point to point, and the spacetime may possess intrinsic curvature.
2.9.1 The Minkowski Line Element in a Local Inertial Frame
In a local inertial frame we use the coordinates \( \xi^\alpha \), defined as:
The Minkowski line element is:
where \( \eta_{\alpha\beta} \) is the Minkowski metric:
Therefore, the line element can also be written explicitly as:
This form describes flat spacetime in an inertial coordinate system.
2.9.2 Coordinate Transformation to a General System
We now introduce an arbitrary coordinate system \(x^\mu\). The original inertial coordinates \(\xi^\alpha\) are regarded as functions of the new coordinates:
Using the chain rule, the differentials of the original coordinates are related to the differentials of the new coordinates by
Similarly,
Substituting these expressions into the Minkowski line element gives
This expression shows that the components describing the metric can become position-dependent when a non-inertial or curvilinear coordinate system is used. This does not, by itself, mean that spacetime is intrinsically curved. A coordinate transformation can change the form and position dependence of the metric components while leaving the spacetime flat.
2.9.3 Definition of the General Metric Tensor
The expression obtained above motivates the definition of the metric components in the new coordinate system:
With this definition, the line element takes the general form
This equation expresses the spacetime interval in any coordinate system.
For the coordinate transformation considered above, \(g_{\mu\nu}\) is simply the Minkowski metric expressed in the new coordinates. The spacetime therefore remains flat, even though the metric components may no longer be constant.
In general relativity, however, the metric tensor \(g_{\mu\nu}\) is not restricted to metrics that can be obtained from the Minkowski metric by a coordinate transformation. Instead, \(g_{\mu\nu}\) is a general tensor field that can describe intrinsically curved spacetime.
2.9.4 Properties of the Metric Tensor
The metric tensor has several important properties.
-
Symmetry:
\begin{align} g_{\mu\nu}=g_{\nu\mu}. \end{align}
The metric tensor is symmetric in its two indices. For the metric obtained from the Minkowski metric by a coordinate transformation, this symmetry follows directly from the symmetry of \(\eta_{\alpha\beta}\). In general relativity, the metric tensor is likewise defined to be symmetric.
-
Inverse metric:
\begin{align} g^{\mu\sigma}g_{\sigma\nu} = \delta^\mu{}_{\nu}. \end{align}
Here \(g^{\mu\nu}\) is the inverse metric and \(\delta^\mu{}_{\nu}\) is the Kronecker delta. The inverse metric is defined so that the contraction of \(g^{\mu\nu}\) with \(g_{\mu\nu}\) produces the identity tensor.
-
Covariant and contravariant components:
The metric is written as \(g_{\mu\nu}\), with both indices in the covariant position, while its inverse is written as \(g^{\mu\nu}\), with both indices in the contravariant position. The position of an index indicates whether that index is covariant or contravariant.
2.9.5 Importance of the Metric in Relativity
The metric tensor contains the information needed to describe the local geometry of spacetime. It determines the spacetime interval and the inner products of vectors, and therefore also determines the causal structure and, where applicable, the angles between vectors. Together with its derivatives, the metric determines the curvature of spacetime.
In general relativity, gravity is described geometrically in terms of the curvature of spacetime. The metric tensor is therefore the fundamental field from which the geometric quantities of the theory are constructed.
The Einstein field equations relate the metric \(g_{\mu\nu}\) to the distribution of matter and energy represented by the stress-energy tensor \(T_{\mu\nu}\). Given suitable matter content together with appropriate initial and boundary conditions, the field equations determine the spacetime geometry, subject to the freedom to choose coordinates.
Once the metric is known, the Christoffel symbols, curvature tensors and geodesics can be calculated from it.
Thus, the metric provides the starting point for the geometric description of gravity.
2.9.6 Number of Independent Components
The metric tensor \(g_{\mu\nu}\) is represented by a \(4\times4\) matrix and therefore has 16 components in total.
However, the metric tensor is symmetric:
Therefore, the components above and below the diagonal are identical. Only the four diagonal components and the six independent off-diagonal components need to be specified.
Equivalently, in \(n\) dimensions, a symmetric rank-\((0,2)\) tensor has
independent components. Thus, in four-dimensional spacetime, the metric tensor has 10 independent components.
2.9.7 Key Points and Intuition
-
The metric tensor \(g_{\mu\nu}\) defines the spacetime interval through:
\begin{align} ds^2=g_{\mu\nu}dx^\mu dx^\nu. \end{align}
- This relation is valid in any coordinate system, provided that the metric components and coordinate differentials are expressed in the same coordinate system.
-
The metric tensor is symmetric:
\begin{align} g_{\mu\nu}=g_{\nu\mu}. \end{align}
- The metric transforms as a rank-\((0,2)\) tensor under coordinate transformations.
- The metric determines the local geometric structure of spacetime, including spacetime intervals, inner products, causal structure and volume elements.
-
In general coordinates, the metric components may depend on position:
\begin{align} g_{\mu\nu}=g_{\mu\nu}(x). \end{align}
-
The Minkowski metric is the special case:
\begin{align} g_{\mu\nu}=\eta_{\mu\nu}. \end{align}
- The metric is the fundamental geometric object from which the Levi-Civita connection and curvature are constructed.
Intuitive Picture
In special relativity, the spacetime interval in inertial coordinates is given by:
This corresponds to the Minkowski metric, whose components are constant in inertial coordinates.
In general relativity, the metric is allowed to vary from point to point. The spacetime interval is therefore written in the general form:
The metric can therefore be thought of as a local rule that determines how spacetime intervals and inner products are measured at each point.
A change of coordinates can change the numerical values of the metric components without changing the underlying geometry. For example, flat spacetime can have position-dependent metric components when described using curvilinear coordinates.
In general relativity, however, position dependence of the metric does not by itself imply curvature. A general metric field can describe genuine intrinsic curvature of spacetime, characterized by a nonzero Riemann curvature tensor. Such curvature cannot be removed throughout a finite region simply by changing coordinates.
Table Overview
| Quantity | Meaning |
|---|---|
| \(g_{\mu\nu}(x)\) | Metric tensor; determines the local geometry and spacetime interval |
| \(g_{\mu\nu}=g_{\nu\mu}\) | Symmetry of the metric tensor |
| \(g^{\mu\sigma}g_{\sigma\nu}=\delta^\mu{}_\nu\) | Definition of the inverse metric |
| \(ds^2=g_{\mu\nu}dx^\mu dx^\nu\) | General expression for the spacetime interval |
| \(g_{\mu\nu}=\eta_{\mu\nu}\) | Minkowski metric; flat spacetime in inertial coordinates |
| \(g_{\mu\nu}(x)\) | General position-dependent metric field |
| \(\Gamma^\lambda{}_{\mu\nu}\) | Levi-Civita connection constructed from the metric and its first derivatives |
| \(R^\rho{}_{\sigma\mu\nu}\) | Riemann curvature tensor constructed from the connection and its derivatives |
2.10 The Riemann Curvature Tensor
The Riemann curvature tensor is one of the most important geometric objects in general relativity. It describes the intrinsic curvature of spacetime and characterizes how a vector changes when it is parallel transported around an infinitesimal closed loop.
In general relativity, spacetime curvature is related to the distribution of energy and momentum through the Einstein field equations.
In flat spacetime, the Riemann curvature tensor vanishes:
In this chapter, we will derive the Riemann tensor in two ways:
- Via the commutator of two covariant derivatives
- Via the method of geodesic deviation
2.10.1 Derivation via the Commutator of Covariant Derivatives
Using the concept of parallel transport, we will derive the expression for the Riemann curvature tensor.
An intuitive example of curvature can be found on the surface of the Earth. Suppose we transport a vector along a path from the North Pole to the equator, then turn by \(90^\circ\), continue along the equator, and finally return to the North Pole along another meridian. If the vector is parallel transported along the entire path, its direction upon return can differ from its initial direction. This difference is a consequence of the intrinsic curvature of the surface.
In a similar way, we can parallel transport a vector around an infinitesimal closed loop on a manifold. The change in the vector after completing the loop is directly related to the Riemann curvature tensor. In flat spacetime, the Riemann tensor vanishes, and parallel transport around an infinitesimal closed loop produces no intrinsic rotation of the vector.
We define parallel transport as transport for which the covariant derivative of the vector along the transport direction vanishes. To derive the Riemann tensor, we investigate how the result of applying two covariant derivatives depends on their order. The commutator of the covariant derivatives provides a direct way to characterize the curvature of the connection.
2.10.1.1 Covariant Derivative Commutator
A commutator measures the difference between applying two operations in opposite orders. For two operators \(A\) and \(B\), it is defined as:
For covariant derivatives, we therefore consider:
In flat Cartesian coordinates, the Christoffel symbols vanish and the covariant derivative reduces to the ordinary partial derivative. Since partial derivatives commute for sufficiently smooth fields,
the commutator vanishes.
In a general coordinate system, the Christoffel symbols need not vanish, even when spacetime is flat. The covariant derivatives can therefore contain nonzero connection terms. Nevertheless, for the Levi-Civita connection of flat spacetime, the Riemann curvature tensor still vanishes.
In a genuinely curved spacetime, the covariant derivatives generally do not commute. Their commutator is therefore directly related to the Riemann curvature tensor, which provides a coordinate-independent description of the intrinsic curvature of spacetime.
2.10.1.2 Derivation of the Riemann Tensor
We derive the Riemann tensor by applying the commutator of two covariant derivatives to a contravariant vector \(V^\rho\). Its covariant derivative is
The quantity \(\nabla_\nu V^\rho\) is a tensor of type \((1,1)\), with one contravariant index \(\rho\) and one covariant index \(\nu\). Its second covariant derivative is therefore
Substituting the expression for the first covariant derivative gives
Interchanging \(\mu\) and \(\nu\), we obtain
We now subtract the two expressions. The second partial derivatives cancel because the coordinate derivatives commute:
The remaining terms containing first derivatives of \(V^\rho\) or \(V^\lambda\) cancel after grouping them and using the symmetry of the Levi-Civita connection,
The terms that remain are all proportional to \(V^\sigma\). After collecting these terms, we obtain
We define the expression in parentheses as the Riemann curvature tensor:
The commutator therefore takes the compact form
This equation shows that the Riemann tensor characterizes the failure of two covariant derivatives to commute when acting on a vector. Equivalently, it characterizes the curvature of the connection and is directly related to the change of a vector under parallel transport around an infinitesimal closed loop.
2.10.1.3 Alternative Geometrical Interpretation
The same result can be understood geometrically by considering parallel transport around an infinitesimal loop. Starting from a point \(A\), transport a vector first in the \(x^\nu\) direction and then in the \(x^\mu\) direction. Alternatively, transport it first in the \(x^\mu\) direction and then in the \(x^\nu\) direction.
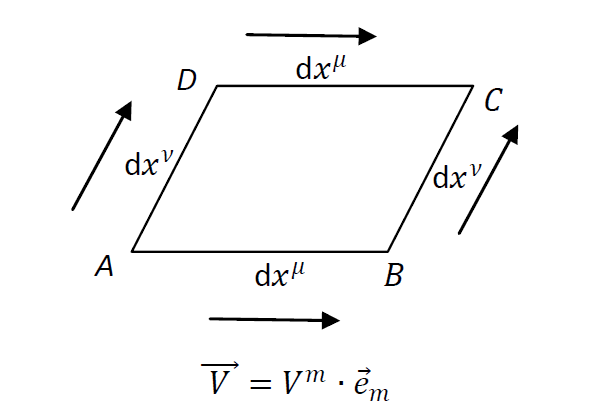
If the Riemann curvature tensor vanishes, the two procedures give the same result to the relevant infinitesimal order. If the Riemann tensor is nonzero, the two resulting vectors generally differ. The difference is determined by the Riemann tensor.
For a contravariant vector, the commutator derived above gives
Thus, the change produced by parallel transport around an infinitesimal loop is proportional to the combination
with the precise sign depending on the orientation chosen for the loop and on the convention used for the Riemann tensor.
The Riemann tensor therefore acts as a linear map on the vector \(V^\sigma\). It is not the magnitude of the resulting difference vector. Rather, for fixed \(\mu\) and \(\nu\), it determines the components of the change associated with the infinitesimal loop.
The Christoffel symbols describe the connection and depend on the chosen coordinate system. They can be made to vanish at a single point by choosing a locally inertial coordinate system. The Riemann tensor, however, represents intrinsic curvature and cannot in general be eliminated throughout a finite region by a coordinate transformation.
2.10.1.4 Definition of the Riemann Tensor
With the convention used above, the Riemann curvature tensor is defined by
Equivalently, using a comma to denote a partial derivative,
The Riemann tensor is antisymmetric in its last two indices:
For a covector \(V_\rho\), the corresponding commutator has the opposite sign:
The different signs for vectors and covectors arise from the different transformation rules of contravariant and covariant components under a covariant derivative.
2.10.1.5 Conclusion
The Riemann curvature tensor arises naturally from the non-commutativity of covariant derivatives. For a contravariant vector,
Thus, the Riemann tensor characterizes the intrinsic curvature of spacetime through the failure of parallel transport to be independent of the path around an infinitesimal closed loop. In flat spacetime, the Riemann tensor vanishes, whereas in a genuinely curved spacetime it is generally nonzero.
2.10.2 Derivation of the Riemann Tensor via Geodesic Deviation
In the previous section, we derived the Riemann tensor from the commutator of covariant derivatives. A second, physically important interpretation arises from the relative acceleration of nearby freely falling particles. This phenomenon is known as geodesic deviation.
Consider two particles following two infinitesimally close geodesics. Let \(x^\alpha(\tau)\) describe the reference geodesic and let \(y^\alpha(\tau)\) describe the neighboring geodesic. Locally, their separation can be represented to first order by the deviation four-vector \(\xi^\alpha(\tau)\):
Here \(\tau\) is chosen as a common affine parameter for the two nearby geodesics, and it coincides with the proper time along the reference timelike geodesic. The tangent four-velocity of the reference geodesic is
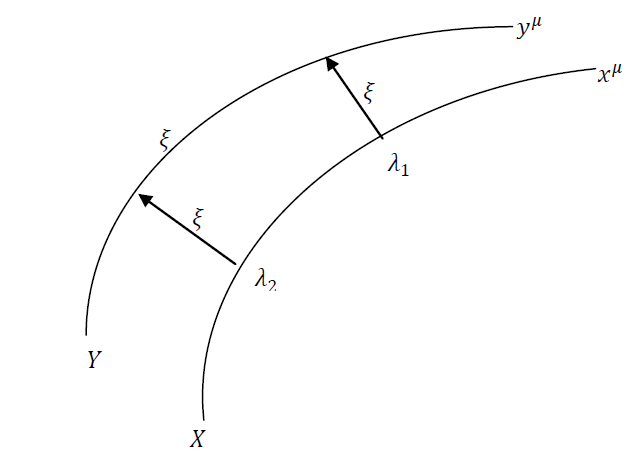
The aim is to derive the geodesic deviation equation, which relates the relative covariant acceleration of the two nearby geodesics to the Riemann curvature tensor:
Here is:
This equation shows that spacetime curvature produces relative acceleration between neighboring freely falling particles. In a flat spacetime, where the Riemann tensor vanishes, the relative covariant acceleration vanishes as well.
2.10.2.1 Geodesic Equations for the Two Particles
Each freely falling particle follows a geodesic. For the reference geodesic \(x^\alpha(\tau)\), the geodesic equation is
For the neighboring geodesic \(y^\alpha(\tau)\), the corresponding equation is
Since the separation \(\xi^\alpha\) is infinitesimal, quantities evaluated at \(y\) can be expanded about the reference position \(x\) to first order in \(\xi^\alpha\).
2.10.2.2 First-Order Expansion of the Christoffel Symbol
For a sufficiently smooth function of several coordinates, the first-order Taylor expansion is
Applying this expansion to the Christoffel symbol gives
We retain only terms that are first order in \(\xi^\alpha\) or \(d\xi^\alpha/d\tau\). Products such as \(\xi^\alpha d\xi^\beta/d\tau\) and \((d\xi^\alpha/d\tau)(d\xi^\beta/d\tau)\) are second order in the separation and are therefore neglected.
2.10.2.3 Linearizing the Neighboring Geodesic
Substitute \(y^\alpha=x^\alpha+\xi^\alpha\) into the geodesic equation for the neighboring particle. Using
and the first-order expansion of the Christoffel symbols, we obtain
Keeping only terms that are first order in the separation gives
The terms that are quadratic in the separation, such as \[ \xi^\sigma \frac{d\xi^\mu}{d\tau} \] and \[ \frac{d\xi^\mu}{d\tau} \frac{d\xi^\nu}{d\tau}, \] have been neglected.
The first and third terms cancel because the reference worldline itself satisfies the geodesic equation:
We therefore obtain the linearized coordinate expression
2.10.2.4 Covariant First Derivative of the Separation Vector
The ordinary derivative \(d\xi^\alpha/d\tau\) describes only the change of the components of the separation vector. In a curved coordinate system, the basis vectors can also change from point to point. Therefore, the ordinary derivative is not by itself a covariant description of the change of the vector.
We therefore introduce the covariant derivative of the separation vector along the reference worldline:
Applying the same covariant differentiation rule once more gives the second covariant derivative:
Substituting equation (\ref{eq:R262}) gives
2.10.2.5 Using the Geodesic Equation
The derivative of the four-velocity is obtained from the geodesic equation:
Furthermore, because the Christoffel symbols depend on position, their derivative along the reference worldline is
Substituting these relations and equation (\ref{eq:R261}) into the expression for the second covariant derivative, the terms containing \(d\xi^\sigma/d\tau\) cancel. After relabeling dummy indices and using the symmetry
we obtain
2.10.2.6 Identification of the Riemann Tensor
The expression in parentheses is precisely the component form of the Riemann curvature tensor introduced in Section 2.10.1:
Consequently, equation (\ref{eq:R263}) becomes
This is the geodesic deviation equation. It states that the relative covariant acceleration of two nearby freely falling particles is determined by the Riemann curvature tensor.
2.10.2.7 Physical Interpretation
The result has an important physical interpretation. Two freely falling particles can each follow a geodesic, yet their separation can change because spacetime is intrinsically curved. The Riemann tensor determines this relative covariant acceleration through the geodesic deviation equation.
In Newtonian language, this effect corresponds to tidal acceleration. Two particles falling toward the same massive body do not generally remain at a constant separation: their trajectories can converge or diverge depending on their relative positions and velocities.
If \(R^\alpha{}_{\mu\sigma\nu}=0\) throughout a region, the spacetime geometry is flat in that region. If the Riemann tensor is nonzero at a point, the spacetime is intrinsically curved at that point.
2.10.2.8 Connection with the Previous Derivation
In Section 2.10.1, the Riemann tensor was obtained from the commutator of covariant derivatives. Here the same tensor appears in a different physical setting: the relative covariant acceleration of neighboring geodesics.
Thus, the two derivations give the same geometric object from two complementary viewpoints:
- Commutator viewpoint: curvature is revealed by the non-commutativity of covariant derivatives when acting on a vector.
- Geodesic-deviation viewpoint: curvature is revealed physically through the relative covariant acceleration of neighboring freely falling particles.
Both descriptions express the same underlying geometric property of spacetime: intrinsic curvature.
2.10.2.9 Key Points and Intuition
- Two nearby freely falling particles follow neighboring geodesics.
- Their separation is described by the deviation four-vector \(\xi^\alpha\).
- The ordinary derivative of \(\xi^\alpha\) must be replaced by the covariant derivative when describing its change in a curved coordinate system.
- The relative covariant acceleration is governed by the Riemann tensor:
- If the Riemann tensor vanishes throughout a region, there is no intrinsic curvature in that region.
- A nonzero Riemann tensor can produce geodesic deviation, which is physically associated with tidal effects.
Intuition
Imagine two small objects falling freely toward Earth. In a local freely falling frame, the effects of gravity can be eliminated at the location of one freely falling observer. Nevertheless, the two trajectories do not generally remain parallel. One trajectory can move slightly closer to the other or farther away.
This relative change is not caused by the mass of either test particle. Instead, it is a manifestation of the curvature of spacetime. The Riemann tensor characterizes this curvature, while the geodesic deviation equation describes how the curvature affects the separation of neighboring geodesics.
Summary Comparison
| Viewpoint | Mathematical expression | Physical interpretation |
|---|---|---|
| Commutator of covariant derivatives | \([\nabla_\mu,\nabla_\nu]V^\rho = R^\rho{}_{\sigma\mu\nu}V^\sigma\) | Failure of covariant derivatives to commute when acting on a vector |
| Riemann tensor | \(\displaystyle R^\alpha{}_{\mu\sigma\nu} = \frac{\partial\Gamma^\alpha{}_{\mu\nu}}{\partial x^\sigma} - \frac{\partial\Gamma^\alpha{}_{\mu\sigma}}{\partial x^\nu} + \Gamma^\alpha{}_{\sigma\gamma} \Gamma^\gamma{}_{\mu\nu} - \Gamma^\alpha{}_{\nu\gamma} \Gamma^\gamma{}_{\mu\sigma} \) | Intrinsic curvature of spacetime |
| Geodesic deviation | \(\displaystyle \frac{D^2\xi^\alpha}{D\tau^2} = -R^\alpha{}_{\mu\sigma\nu} u^\mu u^\nu\xi^\sigma \) | Relative covariant acceleration of neighboring freely falling particles |
2.11 Symmetries and Independent Components
In the previous section, we derived the Riemann curvature tensor as a combination of derivatives and products of Christoffel symbols. In four-dimensional spacetime, the Riemann tensor \(R^\rho{}_{\sigma\mu\nu}\) has \(4^4=256\) components in total. However, these components are not all independent. In this section, we show how the symmetries of the Riemann tensor reduce the number of independent components to 20.
We first analyze the Riemann tensor in a Local Inertial Frame (LIF), where the Christoffel symbols vanish at the chosen point:
At the same point, the first derivatives of the metric can also be made to vanish:
These conditions hold at the chosen point of the LIF; they do not generally hold throughout a finite region. The second derivatives of the metric generally remain nonzero at that point and therefore contain information about the curvature.
Because the resulting relations are tensor equations, any symmetries derived in the LIF at the chosen point hold in every coordinate system.
2.11.1 Definition and Reformulation
The Riemann tensor is defined as:
At the chosen point of the Local Inertial Frame, all Christoffel symbols vanish:
Therefore, at that point, the Riemann tensor reduces to:
We now lower the first index with the metric:
At the chosen point of the LIF, this becomes:
The Christoffel symbols are expressed in terms of the metric as:
Taking the derivative with respect to \(x^\mu\) gives:
At the chosen point of the LIF, the first derivatives of the metric vanish:
Consequently, the first term on the right-hand side of equation (\ref{eq:R332}) vanishes. Using
we obtain:
Interchanging \(\mu\) and \(\nu\) gives:
Substituting equations (\ref{eq:R333}) and (\ref{eq:R334}) into equation (\ref{eq:R330}), and using the equality of mixed partial derivatives, the terms containing \(\partial^2 g_{\alpha\beta}\) cancel. We obtain:
This is the expression for the Riemann tensor with all four indices lowered at the chosen point of a Local Inertial Frame. It shows explicitly that, at that point, the curvature is determined by the second derivatives of the metric.
The expression immediately shows that the Riemann tensor is antisymmetric under interchange of the last two indices:
Because this is a tensor equation, the relation is valid in every coordinate system, not only in the Local Inertial Frame.
The same metric expression also shows that the Riemann tensor is antisymmetric under interchange of the first two indices:
Combining these two antisymmetries with the symmetry under interchange of the two index pairs gives:
Finally, the Riemann tensor satisfies the first Bianchi identity:
These symmetries are the key to reducing the number of independent components of the Riemann tensor from 256 to 20 in four-dimensional spacetime.
2.11.2 Symmetry Properties
From the expression derived above, together with the properties of the Levi-Civita connection, we obtain the following symmetries of the Riemann tensor with all four indices lowered:
-
Antisymmetry in the last two indices:
\begin{align} R_{\alpha\beta\mu\nu} = - R_{\alpha\beta\nu\mu}. \end{align}
-
Antisymmetry in the first two indices:
\begin{align} R_{\alpha\beta\mu\nu} = - R_{\beta\alpha\mu\nu}. \end{align}
-
Symmetry under interchange of index pairs:
\begin{align} R_{\alpha\beta\mu\nu} = R_{\mu\nu\alpha\beta}. \end{align}
-
First Bianchi identity (cyclic identity):
\begin{align} R_{\alpha\beta\mu\nu} + R_{\alpha\mu\nu\beta} + R_{\alpha\nu\beta\mu} = 0. \end{align}
These symmetry properties significantly reduce the number of independent components of the Riemann tensor.
Antisymmetry means that the tensor changes sign when the corresponding pair of indices is interchanged. Geometrically, this is related to the orientation dependence of the infinitesimal loop used in parallel transport: reversing the orientation of the relevant pair of directions reverses the sign of the resulting curvature contribution.
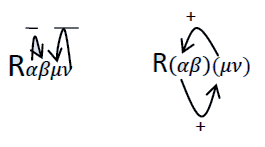
2.11.3 Number of Independent Components
In four-dimensional spacetime, with four possible values for each index, an arbitrary \((0,4)\)-tensor would have
components. The Riemann tensor, however, is subject to the symmetry properties derived above. These symmetries drastically reduce the number of independent components.
-
Antisymmetry in each index pair:
Because the Riemann tensor is antisymmetric in the first two indices and in the last two indices, each pair can be specified by choosing two distinct indices from four:
\begin{align} \binom{4}{2} = 6. \end{align}Therefore, before imposing the symmetry between the two index pairs, there are
\begin{align} \binom{4}{2} \binom{4}{2} = 6\times6 = 36 \end{align}possible combinations.
-
Symmetry under interchange of the two index pairs:
The pair symmetry \[ R_{\alpha\beta\mu\nu} = R_{\mu\nu\alpha\beta} \] means that the two antisymmetric index pairs form a symmetric \(6\times6\) array. A symmetric \(6\times6\) array has
\begin{align} \frac{6(6+1)}{2} = 21 \end{align}independent components.
-
First Bianchi identity:
The first Bianchi identity imposes one additional independent linear constraint on these 21 components in four dimensions. Therefore,
\begin{align} 21-1=20. \end{align}
Thus, in four-dimensional spacetime, the Riemann tensor has only 20 independent components.
2.11.4 Key Points and Intuition
The Riemann tensor \(R_{\rho\sigma\mu\nu}\) possesses several symmetries, which strongly restrict the number of independent components:
-
Antisymmetry in the last two indices:
\begin{align} R_{\rho\sigma\mu\nu} = - R_{\rho\sigma\nu\mu}. \end{align}
-
Antisymmetry in the first two indices:
\begin{align} R_{\rho\sigma\mu\nu} = - R_{\sigma\rho\mu\nu}. \end{align}
-
Symmetry under interchange of index pairs:
\begin{align} R_{\rho\sigma\mu\nu} = R_{\mu\nu\rho\sigma}. \end{align}
-
First Bianchi identity (cyclic identity):
\begin{align} R_{\rho\sigma\mu\nu} + R_{\rho\mu\nu\sigma} + R_{\rho\nu\sigma\mu} = 0. \end{align}
Due to these symmetries, the Riemann tensor in four-dimensional spacetime has only 20 independent components, rather than 256.
Thus, although the original expression for the Riemann tensor appears complex, its symmetry structure means that the entire tensor is determined by only 20 independent components in four-dimensional spacetime. These components encode the possible components of spacetime curvature and therefore form a central part of the geometric description of gravity in general relativity.
Intuition
An arbitrary \((0,4)\)-tensor in four dimensions has
possible components. The Riemann tensor, however, is not an arbitrary tensor. Its indices are related by several symmetry properties:
- Swapping the two indices within either antisymmetric pair changes only the sign.
- Swapping the first index pair with the second index pair leaves the tensor unchanged.
- The Bianchi identity imposes an additional linear relation between different permutations of the indices.
These relations mean that many of the 256 components are not independent. Once the 20 independent components are known, all remaining components are determined by the symmetry properties and the Bianchi identity.
These properties are not accidental. They arise from the geometric properties of the Riemann tensor associated with the Levi-Civita connection, including the torsion-free and metric-compatible properties of that connection.
Table Overview
| Symmetry | Explanation |
|---|---|
| \(R_{\rho\sigma\mu\nu} = -R_{\rho\sigma\nu\mu}\) | Antisymmetry in the last two indices |
| \(R_{\rho\sigma\mu\nu} = -R_{\sigma\rho\mu\nu}\) | Antisymmetry in the first two indices |
| \(R_{\rho\sigma\mu\nu} = R_{\mu\nu\rho\sigma}\) | Symmetry under interchange of the two index pairs |
| \(R_{\rho\sigma\mu\nu} + R_{\rho\mu\nu\sigma} + R_{\rho\nu\sigma\mu} = 0\) | First Bianchi identity (cyclic identity) |
| Initial number | \(4^4=256\) components |
| After antisymmetry | \(\binom{4}{2}\binom{4}{2}=36\) components |
| After pair symmetry | \(\frac{6(6+1)}{2}=21\) components |
| After Bianchi identity | 20 independent components |
| Total in 4D | 20 independent components |
2.12 Bianchi Identity and Ricci Tensor
The Bianchi identity plays a crucial role in general relativity and, in particular, in the derivation and consistency of Einstein's field equations. From the Riemann curvature tensor, we can derive two important curvature quantities by contraction: the Ricci tensor and the Ricci scalar.
In this section, we introduce the differential Bianchi identity and explain how its contracted form leads to the Einstein tensor and its covariant conservation.
2.12.1 Bianchi Identity
The differential Bianchi identity for the Riemann tensor is:
This identity expresses a cyclic relation among the covariant derivatives of the Riemann tensor. It is the differential counterpart of the algebraic Bianchi identity introduced in Section 2.11.
To demonstrate the identity explicitly, consider the origin of a Local Inertial Frame. At the chosen point, the Christoffel symbols vanish:
Consequently, at that point the Riemann tensor can be expressed entirely in terms of second derivatives of the metric:
Because the Christoffel symbols vanish at the chosen point, the connection terms in the covariant derivative of the Riemann tensor also vanish there. Therefore, at that point:
Substituting the expression for the Riemann tensor gives:
The same procedure can be applied to the second term in the Bianchi identity. Replacing the indices in the Riemann tensor according to the cyclic permutation
we obtain:
The third term is obtained in the same way:
Adding these three expressions, and using the symmetry of the metric tensor together with the commutativity of ordinary partial derivatives, every term cancels with another term. Hence, at the chosen point:
Although the derivation was performed in a Local Inertial Frame at one point, the resulting equation is a tensorial identity. Therefore, if it holds in one coordinate system at the chosen point, it holds in every coordinate system. Thus the differential Bianchi identity is a general geometric identity of the Riemann tensor:
This identity will be important when contracting the Riemann tensor. Its contracted form leads to the contracted Bianchi identity, which in turn implies the covariant conservation of the Einstein tensor:
This provides an essential consistency condition for Einstein's field equations, because the energy-momentum tensor must satisfy the corresponding covariant conservation law.
2.12.2 Contracted Bianchi Identity
The differential Bianchi identity can be contracted to obtain an important relation involving the Ricci tensor \(R_{\mu\nu}\) and the Ricci scalar \(R\). The result is the contracted Bianchi identity:
Using metric compatibility,
the contracted Bianchi identity can be written as:
The quantity in parentheses is defined as the Einstein tensor:
Therefore, the contracted Bianchi identity becomes:
This identity is essential for the consistency of Einstein's field equations. When the Einstein field equations relate the Einstein tensor to the energy-momentum tensor, the same geometric identity requires the corresponding covariant conservation law for the matter source:
Thus, the contracted Bianchi identity provides the geometric basis for the local covariant conservation of energy and momentum in general relativity. More precisely, this conservation law follows from the Einstein field equations together with the contracted Bianchi identity.
2.12.3 Key Points and Intuition
-
The differential Bianchi identity is a fundamental identity satisfied by
the Riemann curvature tensor:
\begin{align} \nabla_\lambda R^\rho{}*{\sigma\mu\nu} + \nabla*\mu R^\rho{}*{\sigma\nu\lambda} + \nabla*\nu R^\rho{}_{\sigma\lambda\mu} = 0. \end{align}
-
Contracting the differential Bianchi identity twice gives the contracted
Bianchi identity:
\begin{align} \nabla^\mu \left( R_{\mu\nu} - \frac{1}{2}g_{\mu\nu}R \right) = 0. \end{align}
- The quantity \[ G_{\mu\nu} = R_{\mu\nu} - \frac{1}{2}g_{\mu\nu}R \] is called the Einstein tensor.
-
The Einstein tensor is identically divergence-free:
\begin{align} \nabla^\mu G_{\mu\nu}=0. \end{align}
-
Through Einstein's field equations, this geometric identity is connected
to the covariant conservation of the energy-momentum tensor:
\begin{align} \nabla^\mu T_{\mu\nu}=0. \end{align}
Intuition
The Riemann tensor is not an arbitrary description of curvature. Its components must satisfy additional geometric consistency conditions, including the differential Bianchi identity. The identity expresses the fact that the different ways in which curvature varies are not independent of one another.
The contracted Bianchi identity is especially important because it produces a geometrically conserved tensor:
This is precisely the mathematical property required on the geometric side of Einstein's field equations. Since the Einstein tensor is related to the energy-momentum tensor, the field equations imply the corresponding covariant conservation law for matter:
In this sense, the Bianchi identity provides the bridge between the geometry of spacetime and the local covariant conservation of energy and momentum in general relativity.
Table Overview
| Quantity | Meaning |
|---|---|
| Differential Bianchi identity | Differential identity satisfied by the Riemann curvature tensor |
| Contracted Bianchi identity | \(\nabla^\mu(R_{\mu\nu}-\tfrac{1}{2}g_{\mu\nu}R)=0\) |
| Einstein tensor | \(G_{\mu\nu}=R_{\mu\nu}-\tfrac{1}{2}g_{\mu\nu}R\) |
| Geometric conservation law | \(\nabla^\mu G_{\mu\nu}=0\) |
| Physical conservation law | \(\nabla^\mu T_{\mu\nu}=0\), when the Einstein field equations are satisfied |
2.12.4 The Ricci Tensor
The energy-momentum tensor that appears in Einstein's field equations is a rank-2 tensor. For this reason, we need a rank-2 curvature tensor that can be obtained from the rank-4 Riemann tensor. This tensor is called the Ricci tensor.
The Ricci tensor is obtained by contracting the Riemann tensor. Contraction means summing over one upper and one lower index, thereby reducing the rank of a tensor by two.
Using the Riemann tensor in mixed-index form, the Ricci tensor is defined by:
Equivalently, starting from the fully covariant Riemann tensor, the same contraction can be written as:
Thus, the contraction of the Riemann tensor produces a rank-2 tensor. For the Levi-Civita connection, the Ricci tensor is symmetric:
The Ricci tensor therefore contains part of the curvature information encoded in the Riemann tensor, but in a reduced form. In four-dimensional spacetime, the Riemann tensor has 20 independent components, whereas the symmetric Ricci tensor has 10 independent components. The remaining curvature information is contained in the Weyl tensor.
2.12.4 The Ricci Scalar
The Ricci tensor can be contracted once more with the inverse metric. This produces a scalar quantity called the Ricci scalar:
The Ricci scalar is therefore the trace of the Ricci tensor.
The metric \(g_{\mu\nu}\), the Ricci tensor \(R_{\mu\nu}\), and the Ricci scalar \(R\) are important building blocks of Einstein's field equations. Together with the Einstein tensor, they provide the geometric quantities needed to formulate the gravitational field equations.
The contracted Bianchi identity introduced earlier guarantees the covariant conservation property of the Einstein tensor:
2.12.5 Key Points and Intuition
-
The Ricci tensor \(R_{\mu\nu}\) is obtained by contracting the Riemann tensor:
\begin{align} R_{\mu\nu} = R^\lambda{}_{\mu\lambda\nu}. \end{align}
-
Equivalently, using the fully covariant Riemann tensor:
\begin{align} R_{\mu\nu} = g^{\alpha\beta}R_{\alpha\mu\beta\nu}. \end{align}
-
The Ricci tensor is a rank-2 tensor and, for the Levi-Civita connection,
is symmetric:
\begin{align} R_{\mu\nu}=R_{\nu\mu}. \end{align}
- The Ricci tensor contains curvature information associated, among other things, with the focusing or defocusing of bundles of geodesics.
-
The Ricci scalar \(R\) is obtained by contracting the Ricci tensor with the
inverse metric:
\begin{align} R = g^{\mu\nu}R_{\mu\nu}. \end{align}
- The Ricci scalar is a scalar quantity and therefore has a coordinate-independent value at a given spacetime event.
- The Riemann tensor contains the complete local curvature information, while the Ricci tensor and Ricci scalar contain particular contractions of that information.
Intuition
Think of a small bundle of freely falling particles or light rays. As the particles or rays move through spacetime, the bundle can converge or diverge. The Ricci tensor contributes directly to this focusing behavior of geodesic bundles.
More precisely, the Ricci tensor describes the part of the curvature that contributes to the expansion and focusing of geodesic congruences. The complete curvature information is contained in the Riemann tensor, which also contains the tidal, shear, and rotational curvature information not captured by the Ricci tensor alone.
The Riemann tensor contains the complete local information about how spacetime curvature acts on vectors and directions. The Ricci tensor is obtained from this full curvature tensor by contraction and therefore retains only part of that information.
The Ricci scalar is an even stronger reduction. It compresses the Ricci tensor into a single scalar quantity:
- Riemann tensor = complete local curvature information
- Ricci tensor = contracted curvature associated, among other things, with geodesic focusing
- Ricci scalar = trace of the Ricci tensor, giving one scalar curvature quantity
It is important to note that the Ricci scalar does not contain all the curvature information of spacetime. Different spacetimes can have the same Ricci scalar while having different Ricci tensors or different Riemann tensors.
Table Overview
| Quantity | Definition | Interpretation |
|---|---|---|
| Riemann tensor | \(R^\rho{}_{\sigma\mu\nu}\) | Complete local curvature information |
| Ricci tensor | \(R_{\mu\nu}=R^\lambda{}_{\mu\lambda\nu}\) | Contracted curvature; contributes to geodesic focusing |
| Ricci scalar | \(R=g^{\mu\nu}R_{\mu\nu}\) | Trace of the Ricci tensor; one scalar curvature quantity |
| Einstein tensor | \(G_{\mu\nu}=R_{\mu\nu}-\tfrac{1}{2}g_{\mu\nu}R\) | Symmetric divergence-free tensor appearing in Einstein's field equations |
2.13 Energy-Momentum Tensor
The ultimate goal of general relativity is to establish a relationship between the geometry of spacetime and the matter and energy that determine its curvature. For this, a suitable mathematical object is needed to describe the physical content of spacetime: the energy-momentum tensor.
In special relativity, mass, energy, and momentum are interconnected. This relationship is expressed through the invariant energy-momentum relation:
Using the Minkowski metric introduced earlier, with \(\eta_{\mu\nu}=\operatorname{diag}(1,-1,-1,-1)\), the squared four-momentum is:
where
Therefore:
Multiplying by \(c^2\), we obtain the familiar energy-momentum relation:
This relation shows that energy and momentum are interconnected components of the relativistic description of matter. In general relativity, not only rest mass but also energy, momentum, and stresses contribute to the gravitational field.
In the Newtonian limit, Poisson's equation describes the gravitational potential \(\Phi\), generated by a mass density \(\rho\) (see Appendix 7, equation (20)):
This raises the question: what is the relativistic generalization of mass or energy density? Is it a scalar, a vector, or something else?
2.13.1 Transformation Properties: The Example of a Dust Cloud
Consider a volume \(dx\,dy\,dz\) filled with non-interacting particles at rest relative to each other, a so-called dust cloud. In the rest frame \(S\) of this cloud, the rest-mass density is:
where \(m_0\) is the invariant rest mass of a particle and \(n_0\) is the particle number density measured in the rest frame.
Now consider another reference frame \(S'\), moving with velocity \(v\) in the \(x\)-direction relative to the dust cloud.
The rest mass \(m_0\) is invariant and therefore does not change under a Lorentz transformation. However, the energy of each particle increases by a factor \(\gamma\):
At the same time, the length of the cloud in the direction of motion is Lorentz contracted. Consequently, the particle number density measured in \(S'\) increases by a factor \(\gamma\):
Therefore, the energy density measured in \(S'\) is:
where
is the energy density in the rest frame.
The appearance of two factors of \(\gamma\) is significant. It shows that the energy density does not transform as a scalar quantity. Its transformation behavior is characteristic of a component of a rank-2 tensor.
2.13.2 The Energy-Momentum Tensor of Dust
We now introduce the four-velocity of the dust particles. Since the coordinates used throughout this chapter are \(x^0=ct\), the four-velocity is defined as:
For an inertial particle,
so that:
Thus:
For a particle of rest mass \(m_0\), the four-momentum is:
In particular, the time component is:
so that \(E=cp^0\).
For a dust cloud, the energy-momentum tensor can therefore be expressed in terms of the rest-mass density and the four-velocity. The resulting energy-momentum tensor is:
where \(\rho_0\) denotes the rest-mass density of the dust. If the rest-energy density \(\varepsilon_0=\rho_0c^2\) is used instead, the equivalent expression is:
The tensor is symmetric:
It is called the energy-momentum tensor, or stress-energy tensor, of pressureless dust.
In the rest frame of the dust, where
the tensor has the form:
This correctly shows that, in the rest frame of pressureless dust, the \(00\)-component represents the energy density.
The energy-momentum tensor provides the link between matter, energy, momentum, and stresses and the curvature of spacetime in Einstein's field equations. In the following sections, we will see how this tensor appears on the right-hand side of Einstein's equations.
2.13.3 Physical Meaning of the Energy-Momentum Tensor
The energy-momentum tensor is a rank-2 tensor. In four-dimensional spacetime it can be represented as a \(4\times4\) matrix:
In the usual formulation of general relativity, the stress-energy tensor is symmetric:
Therefore, although the matrix contains 16 entries, only 10 of them are independent.
The different components have different physical interpretations. The time-time component represents energy density, the mixed time-space components describe energy and momentum fluxes, and the purely spatial components describe stresses such as pressure and shear stress.
Thus, the energy-momentum tensor describes the local distribution of energy, momentum, and mechanical stresses that act as sources of spacetime curvature.
2.13.4 Time-Space Components: Energy Flux
Let us first consider the mixed time-space component \(T^{0x}\). Since the coordinates used throughout this chapter are \(x^0=ct\), the dust energy-momentum tensor is:
Using \(\rho_0=n_0m_0\), \(u^0=\gamma c\), and \(u^x=\gamma v_x\), we obtain:
where
is the particle number density in the frame under consideration, and
is the \(x\)-component of the particle's relativistic three-momentum.
Thus:
The quantity \(np_x\) is the momentum carried across a surface per unit area per unit time. Since each particle carries energy \(E\), the corresponding energy flux in the \(x\)-direction is:
Using \(E=cp^0\) and, for a particle, \(p_x\) in the direction of motion, this is related to the time-space component of the stress-energy tensor by:
Therefore, with the convention \(x^0=ct\), the component \(T^{0x}\) is proportional to the energy flux and differs from the SI energy flux by a factor of \(c\).
Similarly:
- \(T^{0y}\): time-space component associated with energy flux in the \(y\)-direction
- \(T^{0z}\): time-space component associated with energy flux in the \(z\)-direction
Since the stress-energy tensor is symmetric, \(T^{\mu\nu}=T^{\nu\mu}\), we have:
The precise physical interpretation of these components depends on the coordinate convention and on the units used. With \(x^0=ct\), the above relations keep the factors of \(c\) explicit.
2.13.5 Space-Space Components: Momentum Flux and Stress
Now consider components with both indices spatial, denoted by \(T^{ij}\), where \(i,j\in\{x,y,z\}\). For dust:
Here \(p^j\) is the \(j\)-component of the relativistic three-momentum. Therefore:
The quantity \(n v^i\) represents the number of particles crossing a surface per unit area per unit time in the \(i\)-direction. Consequently, \(T^{ij}\) represents the flux of the \(j\)-component of momentum in the \(i\)-direction.
For example:
- \(T^{xz}\): flux of \(z\)-momentum in the \(x\)-direction
- \(T^{xy}\): flux of \(y\)-momentum in the \(x\)-direction
- \(T^{zz}\): flux of \(z\)-momentum in the \(z\)-direction, corresponding to a normal stress and, in a fluid description, to pressure
For a dust cloud in its own rest frame, the spatial components vanish because the particles have no macroscopic relative motion:
Thus, the interpretation of the spatial components as momentum flux becomes especially clear in a frame in which the dust is moving.
Because the tensor is symmetric, we also have:
2.13.6 Summary
- \(T^{00}\) = energy density in the chosen frame
- \(T^{0i}\) and \(T^{i0}\) = time-space components associated with energy flux
- \(T^{ij}\) = flux of momentum component \(j\) in direction \(i\), representing stress such as pressure and shear
This interpretation makes clear why \(T^{\mu\nu}\) is the appropriate tensor for describing the local physical content of a system. It contains information about energy density, momentum density, energy flux, and mechanical stresses, and therefore provides the natural source tensor for the gravitational field in general relativity.
2.13.7 Covariant Differentiation of the Energy-Momentum Tensor
In the flat spacetime of special relativity, local conservation of energy and momentum can be expressed mathematically as:
Equivalently, one may write:
This conservation law is associated with translational invariance through Noether's theorem: invariance under translations in time leads to energy conservation, while invariance under spatial translations leads to momentum conservation.
The equation above expresses local conservation in flat spacetime. The index \(\mu\) labels the particular component of the conserved four-momentum, while the repeated index \(\nu\) is summed over according to the Einstein summation convention.
2.13.8 From Flat to Curved Spacetime
In general relativity, physics is described on a curved spacetime. Ordinary partial derivatives of tensor components do not, in general, transform as tensors. Therefore, the natural tensorial generalization of the flat-spacetime conservation law is expressed using the covariant derivative:
For a rank-2 contravariant tensor, the covariant divergence is explicitly:
This is a tensor equation and is therefore generally covariant, meaning that it has the same geometric meaning in every coordinate system.
In a Local Inertial Frame at a chosen spacetime event, the Christoffel symbols vanish at that event:
Consequently, at that event:
Thus, the equation
expresses local covariant conservation of energy and momentum in curved spacetime. It is the natural general-relativistic conservation law for the stress-energy tensor.
Its consistency with Einstein's field equations is closely related to the contracted Bianchi identity derived in the previous section:
where
Einstein's field equations identify the geometric tensor \(G_{\mu\nu}\) with the energy-momentum tensor \(T_{\mu\nu}\). The divergence-free property of the Einstein tensor therefore provides the corresponding consistency condition:
Thus, the geometry of spacetime and the local covariant conservation of energy and momentum are mathematically compatible with each other. This provides an essential consistency condition for Einstein's field equations.
2.14 Einstein Tensor
The Poisson equation for the gravitational field in classical (Newtonian) mechanics is given by (see equation (Appendix 7 equation 20)):
where \(\Phi\) is the gravitational potential and \(\rho\) is the mass density.
Our goal is now to find a relativistic generalization of this equation. As we saw in Section 2.13.3, the classical mass density \(\rho\) is not sufficient to describe the source of gravity in general relativity. Instead, the energy-momentum tensor \(T^{\mu\nu}\) describes the local distribution and flow of energy and momentum, including energy density, momentum density, pressure, and stresses.
It is therefore natural to assume that Einstein's relativistic field equation should have the following form:
Here \(G^{\mu\nu}\) is the Einstein tensor and \(\kappa\) is a constant to be determined. The Einstein tensor is a symmetric rank-2 tensor constructed from the curvature of spacetime and plays the role of the geometrical side of the field equation.
2.14.1 Requirements for the Einstein Tensor
Based on the physical and mathematical requirements that the field equation must satisfy, the geometrical tensor \(G^{\mu\nu}\) should have the following properties:
- It should vanish in flat spacetime when the curvature vanishes.
- It should be constructed from the curvature of spacetime and, in the simplest construction, depend linearly on the Ricci tensor and Ricci scalar.
- It must be a symmetric rank-2 tensor, like \(T^{\mu\nu}\).
-
It must have zero covariant divergence:
\begin{align} \nabla_\nu G^{\mu\nu}=0, \end{align}so that it is compatible with the conservation law\begin{align} \nabla_\nu T^{\mu\nu}=0. \end{align}
-
In the Newtonian limit, it must reproduce Poisson's equation:
\begin{align} \nabla^2\Phi=4\pi G\rho. \end{align}
The contracted Bianchi identity derived in Section 2.12 is essential for the fourth requirement. It tells us that the required geometrical tensor must be constructed in such a way that its covariant divergence vanishes identically.
In the following sections, we will see why the Ricci tensor alone is not sufficient and how the required combination of the Ricci tensor and Ricci scalar leads to the Einstein tensor.
2.14.2 First Attempt with the Ricci Tensor
As we saw in Section 2.8, in the weak-field Newtonian limit the metric perturbation is related to the gravitational potential by:
It is therefore natural to look for a tensor that, like the Laplacian in Poisson's equation, contains second derivatives of the metric. The Riemann tensor satisfies this requirement and fundamentally describes the curvature of spacetime.
Since we need a rank-2 tensor for the field equation, it is natural to first consider the contracted form of the Riemann tensor: the Ricci tensor. From the convention used in the previous sections, the Riemann tensor is:
By contracting the upper index with the third index, we obtain the Ricci tensor:
Therefore:
We now examine the \(00\)-component in the Newtonian limit. For a weak, static gravitational field, the Christoffel symbols are first order in the metric perturbation \(h_{\mu\nu}\). Consequently, the products of two Christoffel symbols are second order and can be neglected. Furthermore, time derivatives vanish. Therefore:
Because the gravitational field is static, the term containing a time derivative vanishes. The remaining first-order contribution comes from the spatial indices:
Using the previously derived result for the Christoffel symbol in the weak-field approximation:
With the metric signature used here,
so:
Taking the spatial derivative gives:
Therefore:
Substituting
gives:
Using Poisson's equation,
we obtain:
This result shows that the \(00\)-component of the Ricci tensor contains the correct Newtonian source term. This suggests considering a field equation of the form:
In the Newtonian limit, the dominant component of the energy-momentum tensor is:
Comparing this with
would give the candidate coupling constant:
Thus, the Ricci tensor appears at first sight to provide a plausible geometrical quantity for the left-hand side of the field equation. However, this proposal has a fundamental problem: the Ricci tensor does not, in general, have vanishing covariant divergence.
In general relativity, the energy-momentum tensor satisfies the local covariant conservation law:
Taking the covariant divergence of the proposed equation
would therefore require:
However, this is not generally true. The contracted Bianchi identity instead gives:
Therefore, the Ricci tensor alone cannot provide the required left-hand side of Einstein's field equations. We must construct a different rank-2 tensor from the Ricci tensor and the Ricci scalar whose covariant divergence vanishes identically. This leads directly to the Einstein tensor.
2.14.3 Second Attempt
There exists a tensor closely related to the Ricci tensor that is suitable as the left-hand side of the Einstein field equations: the Einstein tensor. It is defined as:
Here \(R\) is the Ricci scalar:
The Einstein tensor already satisfies several requirements:
- It is symmetric, as required by the symmetry of \(T^{\mu\nu}\).
- It is a rank-2 tensor.
- It describes spacetime curvature, since it is directly constructed from the Ricci tensor and the Ricci scalar, which are themselves obtained from the Riemann tensor.
What remains to be shown is that the covariant divergence of the Einstein tensor vanishes identically:
This is essential because the energy-momentum tensor satisfies the local covariant conservation law \(\nabla_\nu T^{\mu\nu}=0\). The geometric tensor appearing on the left-hand side of the field equations must therefore possess the same divergence-free property.
We derive this result from the differential Bianchi identity:
To contract this identity, multiply it by \(g^{\gamma\sigma}g^{\alpha\mu}g^{\beta\nu}\). Because the Levi-Civita connection is metric-compatible,
the metric factors can be moved through the covariant derivatives. We obtain:
For the first term, the contractions of the Riemann tensor produce the Ricci scalar:
Therefore, the first term becomes:
For the second term, use the pair-exchange symmetry of the fully covariant Riemann tensor:
The contraction then gives the Ricci tensor:
Thus, the second term becomes:
For the third term, using the antisymmetry of the Riemann tensor in its last two indices and the definition of the Ricci tensor gives:
After contraction with \(g^{\gamma\sigma}\), the third term becomes:
Substituting the three contracted terms into the Bianchi identity gives:
The last two terms are equal after renaming the dummy index, so they cancel. However, this indicates that the particular contraction above does not yet produce the desired contracted Bianchi identity. A more direct contraction of the differential Bianchi identity is therefore useful.
Starting from the standard equivalent form of the differential Bianchi identity,
contract first with \(g^{\rho\mu}\). This gives:
Contracting once more with \(g^{\sigma\lambda}\) and using metric compatibility gives the contracted Bianchi identity:
Raising the remaining lower index gives the equivalent form:
Using metric compatibility once more, \(\nabla_\nu g^{\mu\nu}=0\), we can write this as:
Therefore:
2.14.4 Conclusion
The Einstein tensor \(G^{\mu\nu}\) is a suitable choice for the left-hand side of the field equation. It is symmetric, constructed from spacetime curvature, and has identically vanishing covariant divergence. This makes it compatible with the covariant conservation law of the energy-momentum tensor.
Therefore, the equation
is a suitable candidate for the general-relativistic field equation. The coupling constant \(\kappa\) will be determined by requiring that the equation reproduce Newtonian gravity in the appropriate weak-field limit.
2.15 Einstein Field Equations
In the previous sections, we derived the two quantities that form the core of the field equations in general relativity:
- The Einstein tensor \(G_{\mu\nu}\), which is constructed from the geometry and curvature of spacetime.
- The energy-momentum tensor \(T_{\mu\nu}\), which describes the local distribution and flow of energy and momentum, including pressure and stresses.
These two quantities are related by:
where \(\kappa\) is a coupling constant to be determined.
2.15.1 Goal: Recovering Newton in the Weak-Field Limit
To determine the value of \(\kappa\), we require that the Einstein field equations reduce to Newtonian gravity in the appropriate limit: weak, static gravitational fields and low velocities. This ensures that general relativity is consistent with Newtonian gravity within its domain of applicability.
2.15.2 Alternative Formulation of the Field Equation
The Einstein field equation can also be written directly in terms of the Ricci tensor. Starting from:
we take the trace by contracting both sides with \(g^{\mu\nu}\). In four-dimensional spacetime:
Using
and
we obtain:
Therefore:
Substituting this result into the original Einstein equation gives:
Hence:
This is called the trace-reversed form of Einstein's field equation. It is completely equivalent to the standard form in four-dimensional spacetime.
The combination \(T_{\mu\nu}-\frac{1}{2}g_{\mu\nu}T\) therefore appears naturally when the Einstein field equations are solved for the Ricci tensor. It is not an alternative definition of the Einstein tensor.
2.15.2.1 Equivalent Forms
Using \(R=-\kappa T\), the trace-reversed equation can also be written as:
Rearranging gives back the standard Einstein field equation:
Thus, the standard and trace-reversed forms contain exactly the same information.
2.15.2.2 Historical Remark
Einstein also used formulations involving the trace of the energy tensor in his early work. Historical notation and sign conventions differ from the modern conventions adopted in this chapter. Such historical equations should therefore be compared with the modern Einstein field equations only after accounting for the differences in conventions.
2.15.2.3 Conclusion
The standard form and the trace-reversed form of Einstein's field equations are completely equivalent in four-dimensional spacetime. The standard form highlights the Einstein tensor:
whereas the trace-reversed form expresses the Ricci tensor directly in terms of the energy-momentum tensor and its trace:
The trace-reversed form is particularly useful when analyzing matter distributions and when taking the Newtonian limit.
2.15.3 Newtonian Limit
In Section 2.8, we saw that in the limit of weak, static gravitational fields and low velocities, the \(00\)-component of the Ricci tensor can be approximated as:
Using Poisson's equation,
we obtain:
We now consider the energy-momentum tensor in the same Newtonian limit. For non-relativistic matter, the dominant component is the energy density:
For slowly moving matter, the spatial components of the four-velocity are much smaller than its time component:
Consequently, the \(00\)-component of the energy-momentum tensor dominates over the components involving spatial indices. Lowering the indices with the approximately Minkowskian metric gives:
The trace of the energy-momentum tensor is:
In the Newtonian limit, the dominant contribution comes from the \(00\) component. Therefore:
We now apply the \(00\)-component of the trace-reversed Einstein equation:
Since \(g_{00}\approx\eta_{00}=1\) in the Newtonian limit:
Thus:
Combining this result with the Newtonian expression for \(R_{00}\) gives:
Therefore:
The Einstein field equations without a cosmological constant therefore take the standard form:
Equivalently:
The trace-reversed form is:
2.15.3.1 Remark 1: Magnitude of the Coupling Constant
The coupling constant has the numerical value:
The extremely small value of this coupling illustrates why gravitational effects are usually weak for ordinary concentrations of matter and energy. Very large concentrations of mass-energy are required to produce strong spacetime curvature on macroscopic scales.
2.15.3.2 Remark 2: Complexity of the Einstein Equations
Despite their relatively compact appearance, the Einstein field equations are mathematically very complex. In four-dimensional spacetime, they can be written as ten distinct component equations for the ten independent components of the symmetric metric \(g_{\mu\nu}\).
The equations are coupled, nonlinear, and second-order partial differential equations in the metric components. They are nonlinear because the metric determines the Christoffel symbols, the Christoffel symbols determine the curvature, and the resulting curvature appears again in the field equations. The metric also occurs in the inverse metric and in the contractions used to construct the Ricci tensor and Ricci scalar.
The ten component equations are not ten independent physical equations. Coordinate freedom and the differential identities satisfied by the Einstein tensor must be taken into account when determining the true gravitational degrees of freedom.
2.15.3.3 Remark 3: Nonlinearity of Gravity
The nonlinearity of the Einstein equations has an important physical meaning. The gravitational field is represented by the spacetime metric itself, and the gravitational field contributes to the geometry that determines the behaviour of the gravitational field. In this sense, gravity can interact with itself.
This is fundamentally different from the classical linear Maxwell equations in vacuum, where the electromagnetic field does not directly act as a source for itself. In general relativity, the nonlinear structure of the field equations allows gravitational fields to interact with one another.
In a quantum description of gravity, this classical self-interaction is associated with interactions among gravitons. This is a quantum-field theoretical interpretation of the classical nonlinearity; the classical Einstein equations themselves do not require the introduction of gravitons.
2.15.3.4 Remark 4: Equations, Constraints, and Coordinate Freedom
The metric \(g_{\mu\nu}\) is symmetric and therefore has ten independent components in four-dimensional spacetime. The Einstein field equations can be expressed as ten component equations:
However, these ten equations are not ten independent physical equations. The Einstein tensor satisfies the contracted Bianchi identity:
These four differential identities are closely related to the four-dimensional coordinate freedom of general relativity. Different coordinate systems can describe the same physical spacetime geometry.
Four coordinate conditions can therefore be imposed to fix the coordinate freedom. The remaining metric components are then subject to constraint equations and dynamical field equations. After all constraints and gauge freedom are properly taken into account, general relativity has two independent local gravitational degrees of freedom, corresponding to the two polarizations of gravitational waves.
2.15.4 Key Points and Intuition
-
The Einstein field equations relate spacetime geometry to energy-momentum:
\begin{align} R_{\mu\nu} - \frac{1}{2}g_{\mu\nu}R = \kappa T_{\mu\nu}. \end{align}
-
The left-hand side is the Einstein tensor:
\begin{align} G_{\mu\nu} = R_{\mu\nu} - \frac{1}{2}g_{\mu\nu}R. \end{align}
- The right-hand side contains the energy-momentum tensor \(T_{\mu\nu}\), which describes energy density, momentum density, energy and momentum fluxes, pressure, and stresses.
-
The coupling constant is fixed by requiring the theory to reproduce
Newtonian gravity in the appropriate weak-field and non-relativistic
limit:
\begin{align} \kappa = \frac{8\pi G}{c^4}. \end{align}
-
The trace-reversed form is:
\begin{align} R_{\mu\nu} = \kappa \left( T_{\mu\nu} - \frac{1}{2}g_{\mu\nu}T \right). \end{align}
-
The trace of the standard Einstein equation gives:
\begin{align} R = -\kappa T. \end{align}
Intuitive Picture
Imagine spacetime as a dynamical four-dimensional geometric structure. Matter and energy influence this geometry, while the resulting geometry determines the inertial motion of freely falling objects.
The analogy of a flexible fabric can be useful as an initial intuition, but it should not be taken literally. Spacetime curvature is intrinsic and does not require an external higher-dimensional space in which spacetime is embedded.
The equation
can therefore be understood schematically as expressing the relationship:
- energy, momentum, pressure, and stresses contribute to spacetime geometry;
- the resulting geometry determines the inertial motion of freely falling matter and radiation.
In weak gravitational fields and at low velocities, the Einstein equations reduce to Newtonian gravity. Recovering this limit is an essential consistency requirement for general relativity.
2.15.5 Table: Important Quantities in the Einstein Field Equations
| Quantity | Meaning / Role |
|---|---|
| \(R_{\mu\nu}\) | Ricci tensor: a contraction of the Riemann curvature tensor |
| \(R\) | Ricci scalar: the scalar obtained by contracting the Ricci tensor |
| \(g_{\mu\nu}\) | Metric tensor: determines spacetime intervals, inner products, and causal structure |
| \(G_{\mu\nu} = R_{\mu\nu} - \frac{1}{2}g_{\mu\nu}R\) | Einstein tensor: the divergence-free geometric tensor appearing in the field equations |
| \(T_{\mu\nu}\) | Energy-momentum tensor: describes energy, momentum, fluxes, pressure, and stresses |
| \(T=g^{\mu\nu}T_{\mu\nu}\) | Trace of the energy-momentum tensor |
| \(\kappa=\frac{8\pi G}{c^4}\) | Coupling constant relating energy-momentum to spacetime geometry |
2.16 Summary of the Final Formula of General Relativity
In the previous sections, we have step by step developed the mathematical framework of general relativity. We introduced the metric tensor, Christoffel symbols, covariant derivatives, the Riemann tensor, the Ricci tensor, the Ricci scalar, the Einstein tensor, and the energy-momentum tensor.
We can now summarize the final field equation and its physical meaning.
2.16.1 Einstein's Fundamental Insight
Einstein's central insight was that gravity is not fundamentally described as a Newtonian force. Instead, gravitational phenomena are encoded in the geometry of spacetime. Matter and energy influence spacetime geometry, while that geometry determines the inertial motion of freely falling objects.
Including the cosmological constant, the Einstein field equation is:
Here \(\Lambda\) is the cosmological constant. Its contribution is especially important on cosmological scales, although the term is present in the field equations at all scales. For many local applications, its contribution is negligibly small and can be omitted:
The left-hand side describes the geometry of spacetime, while the right-hand side describes its energy-momentum content. The constant \(c\) is the speed of light in vacuum, and \(G\) is Newton's gravitational constant.
2.16.2 Vacuum: Outside a Mass
In a vacuum region, the energy-momentum tensor vanishes:
If the cosmological constant is neglected, the Einstein field equation becomes:
Taking the trace gives:
Therefore:
Substituting this result back into the vacuum field equation gives:
These are the vacuum Einstein equations for \(\Lambda=0\). Importantly, \(R_{\mu\nu}=0\) does not imply that the full spacetime is flat. The full Riemann tensor can still be nonzero.
2.16.3 Explanation of the Objects Used
The indices \(\mu\) and \(\nu\) run from 0 to 3 and refer to the four dimensions of spacetime: one time dimension (\(0\)) and three spatial dimensions (\(1=x\), \(2=y\), \(3=z\)).
Because each index can take four values, the Einstein field equation contains \(4\times4=16\) component expressions. However, because the tensors appearing in the equation are symmetric, only 10 of these component equations are distinct.
The Ricci tensor is symmetric:
The metric tensor is also symmetric:
The energy-momentum tensor is symmetric in the standard formulation:
Thus, the independent components can be represented by the symmetric matrix:
Similarly, the metric tensor has the form:
The metric determines spacetime intervals, inner products, causal structure, and geodesics, and therefore determines the spacetime geometry up to coordinate transformations.
The Ricci scalar is obtained by contracting the Ricci tensor:
The energy-momentum tensor can be represented as:
In an appropriate coordinate system, \(T_{00}\) is associated with energy density, \(T_{0i}\) with energy and momentum fluxes, and \(T_{ij}\) with momentum fluxes, pressure, and stresses.
2.16.4 Determination of \(R_{\mu\nu}\)
The Ricci tensor is obtained by contracting the Riemann tensor:
Using the Riemann tensor convention introduced earlier, this gives:
The Christoffel symbols are constructed from the metric and its first derivatives:
Thus, the Ricci tensor depends on the metric and its first and second derivatives. The complete local curvature information, however, is contained in the Riemann tensor rather than in the Ricci tensor alone.
2.16.5 The Schwarzschild Solution
In 1916, Karl Schwarzschild published an exact solution of Einstein's field equations describing the exterior gravitational field of a static, spherically symmetric, non-rotating mass. This solution is known as the Schwarzschild solution.
Using the \(+---\) signature adopted in this chapter, the Schwarzschild metric in standard Schwarzschild coordinates is:
This metric describes the exterior region of the mass, where \(T_{\mu\nu}=0\). For \(\Lambda=0\), it satisfies:
The metric components are:
Thus:
For the motion of a test particle in this spacetime, spherical symmetry and conservation of angular momentum imply that the trajectory can be chosen to lie in a single plane. By an appropriate choice of coordinates, this plane can be taken to be the equatorial plane:
Along such a trajectory, \(d\theta=0\) and \(\sin\theta=1\), so the line element reduces to:
This is a simplification of the line element along the chosen trajectory, not a reduction of the Schwarzschild spacetime itself.
See also Chapter 7.3, “Answer to Questions Concerning Schwarzschild”.
2.16.5.1 Remark 1: Sign Conventions
Different texts use different sign conventions for the Riemann tensor and Ricci tensor. Such choices can change the signs of curvature expressions while leaving the physical content unchanged, provided the convention is used consistently throughout the calculation.
In this chapter we use the metric signature \((+---)\), often called the West Coast convention. The definitions of the Riemann tensor, Ricci tensor, and Einstein tensor used throughout the chapter are based on this convention.
2.16.5.2 Final Remark
The Einstein field equations form a system of coupled, nonlinear, second-order partial differential equations for the spacetime metric. Although the equations can be written compactly, they contain a rich description of gravitational phenomena.
They provide the mathematical framework for finding exact and approximate solutions, including the Schwarzschild solution and cosmological solutions, and they explain phenomena such as the relativistic precession of Mercury, gravitational waves, black holes, gravitational lensing, and the expansion of the universe.
Mass-energy influences spacetime geometry, and spacetime geometry influences the motion of matter and radiation.
2.16.6 Key Points and Intuition
- Einstein's central insight is that gravity is not fundamentally described as a Newtonian force. Gravitational phenomena are encoded in the geometry of spacetime.
-
The Einstein field equations, including the cosmological constant, are:
\begin{align} R_{\mu\nu} - \frac{1}{2}g_{\mu\nu}R + \Lambda g_{\mu\nu} = \frac{8\pi G}{c^4}T_{\mu\nu}. \end{align}For many local applications, the contribution of \(\Lambda\) can be neglected.
-
In vacuum with \(\Lambda=0\), \(T_{\mu\nu}=0\), and therefore:
\begin{align} R_{\mu\nu}=0. \end{align}This does not imply that the full Riemann tensor vanishes.
- The left-hand side of the Einstein equation is constructed from the metric and its derivatives and represents spacetime geometry.
- The right-hand side contains the energy-momentum tensor, which describes energy, momentum, pressure, stresses, and fluxes.
-
The Einstein tensor satisfies the contracted Bianchi identity:
\begin{align} \nabla^\mu G_{\mu\nu}=0. \end{align}
Intuitive Picture
Imagine spacetime as a dynamical four-dimensional geometric structure. Matter and energy influence this geometry, while the resulting geometry determines the inertial motion of freely falling objects.
The analogy of a flexible fabric can be useful as an initial intuition, but it should not be taken literally. Spacetime curvature is intrinsic and does not require an external higher-dimensional space in which spacetime is embedded.
The Einstein equation can therefore be understood schematically as expressing the relationship:
- energy, momentum, pressure, and stresses contribute to spacetime geometry;
- the resulting geometry determines the inertial motion of freely falling matter and radiation.
For example, a planet orbiting a star can be described as following a geodesic of the curved spacetime surrounding the star. In this description, the orbital motion does not require a Newtonian gravitational force as a fundamental interaction.
In the appropriate weak-field and low-velocity limit, the Einstein field equations reduce to Newtonian gravity.
Table: Structure of the Final Equation
| Term | Meaning |
|---|---|
| \(G_{\mu\nu}\) | Geometric side: the divergence-free Einstein tensor |
| \(T_{\mu\nu}\) | Physical side: energy-momentum, including energy density, momentum, pressure, stresses, and fluxes |
| \(\nabla^\mu G_{\mu\nu}=0\) | Contracted Bianchi identity: a geometric differential identity |
| \(\dfrac{8\pi G}{c^4}\) | Coupling constant relating energy-momentum to spacetime geometry |
| \(\Lambda g_{\mu\nu}\) | Cosmological-constant contribution to the field equations |
Table: Important Quantities (Summary)
| Quantity | Meaning / Role |
|---|---|
| \(R_{\mu\nu}\) | Ricci tensor: a contraction of the Riemann curvature tensor |
| \(R\) | Ricci scalar: the scalar obtained by contracting the Ricci tensor |
| \(g_{\mu\nu}\) | Metric tensor: determines spacetime intervals, inner products, and causal structure |
| \(\Lambda g_{\mu\nu}\) | Cosmological-constant contribution to the Einstein field equations |
| \(T_{\mu\nu}\) | Energy-momentum tensor: describes energy, momentum, pressure, stresses, and fluxes |
| \(\dfrac{8\pi G}{c^4}\) | Coupling constant relating energy-momentum to spacetime geometry |
These equations form the mathematical culmination of the geometric framework developed in the preceding sections. The next step is to study particular solutions of the field equations, such as the Schwarzschild solution, cosmological solutions, and solutions describing gravitational waves.